


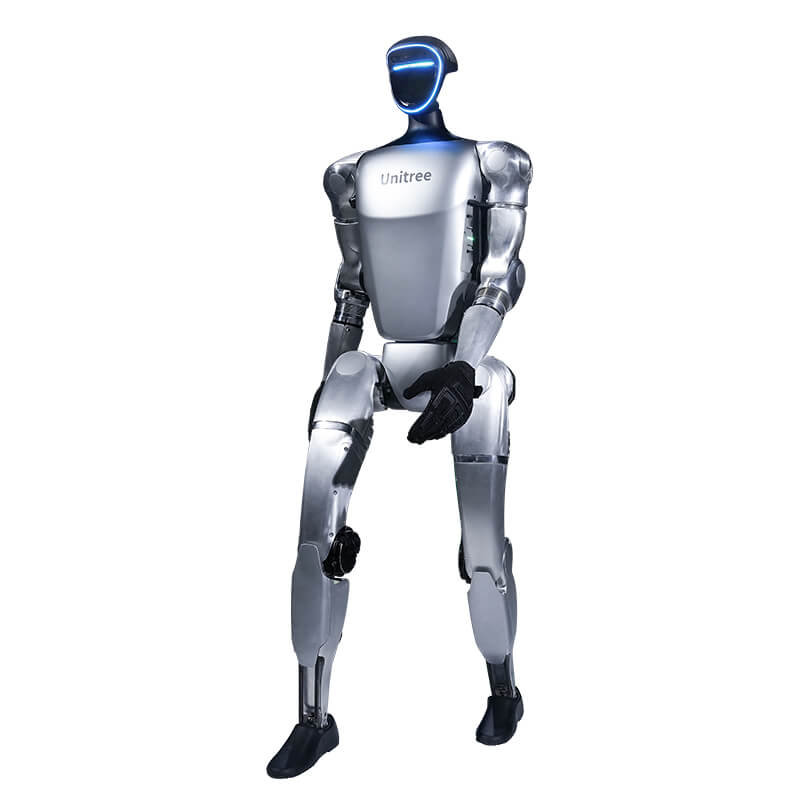
Unitree R1 Edu Pro Humanoid Robot
Secondary development
Degrees of freedom
Optional Orin compute
Total weight


Degrees of freedom
Depth camera
Total weight
Standing height


Weatherized build
Unloaded endurance
LiDAR 360°×189°
Max speed


Optional Jetson Thor
Secondary development
Degrees of freedom
Standing height
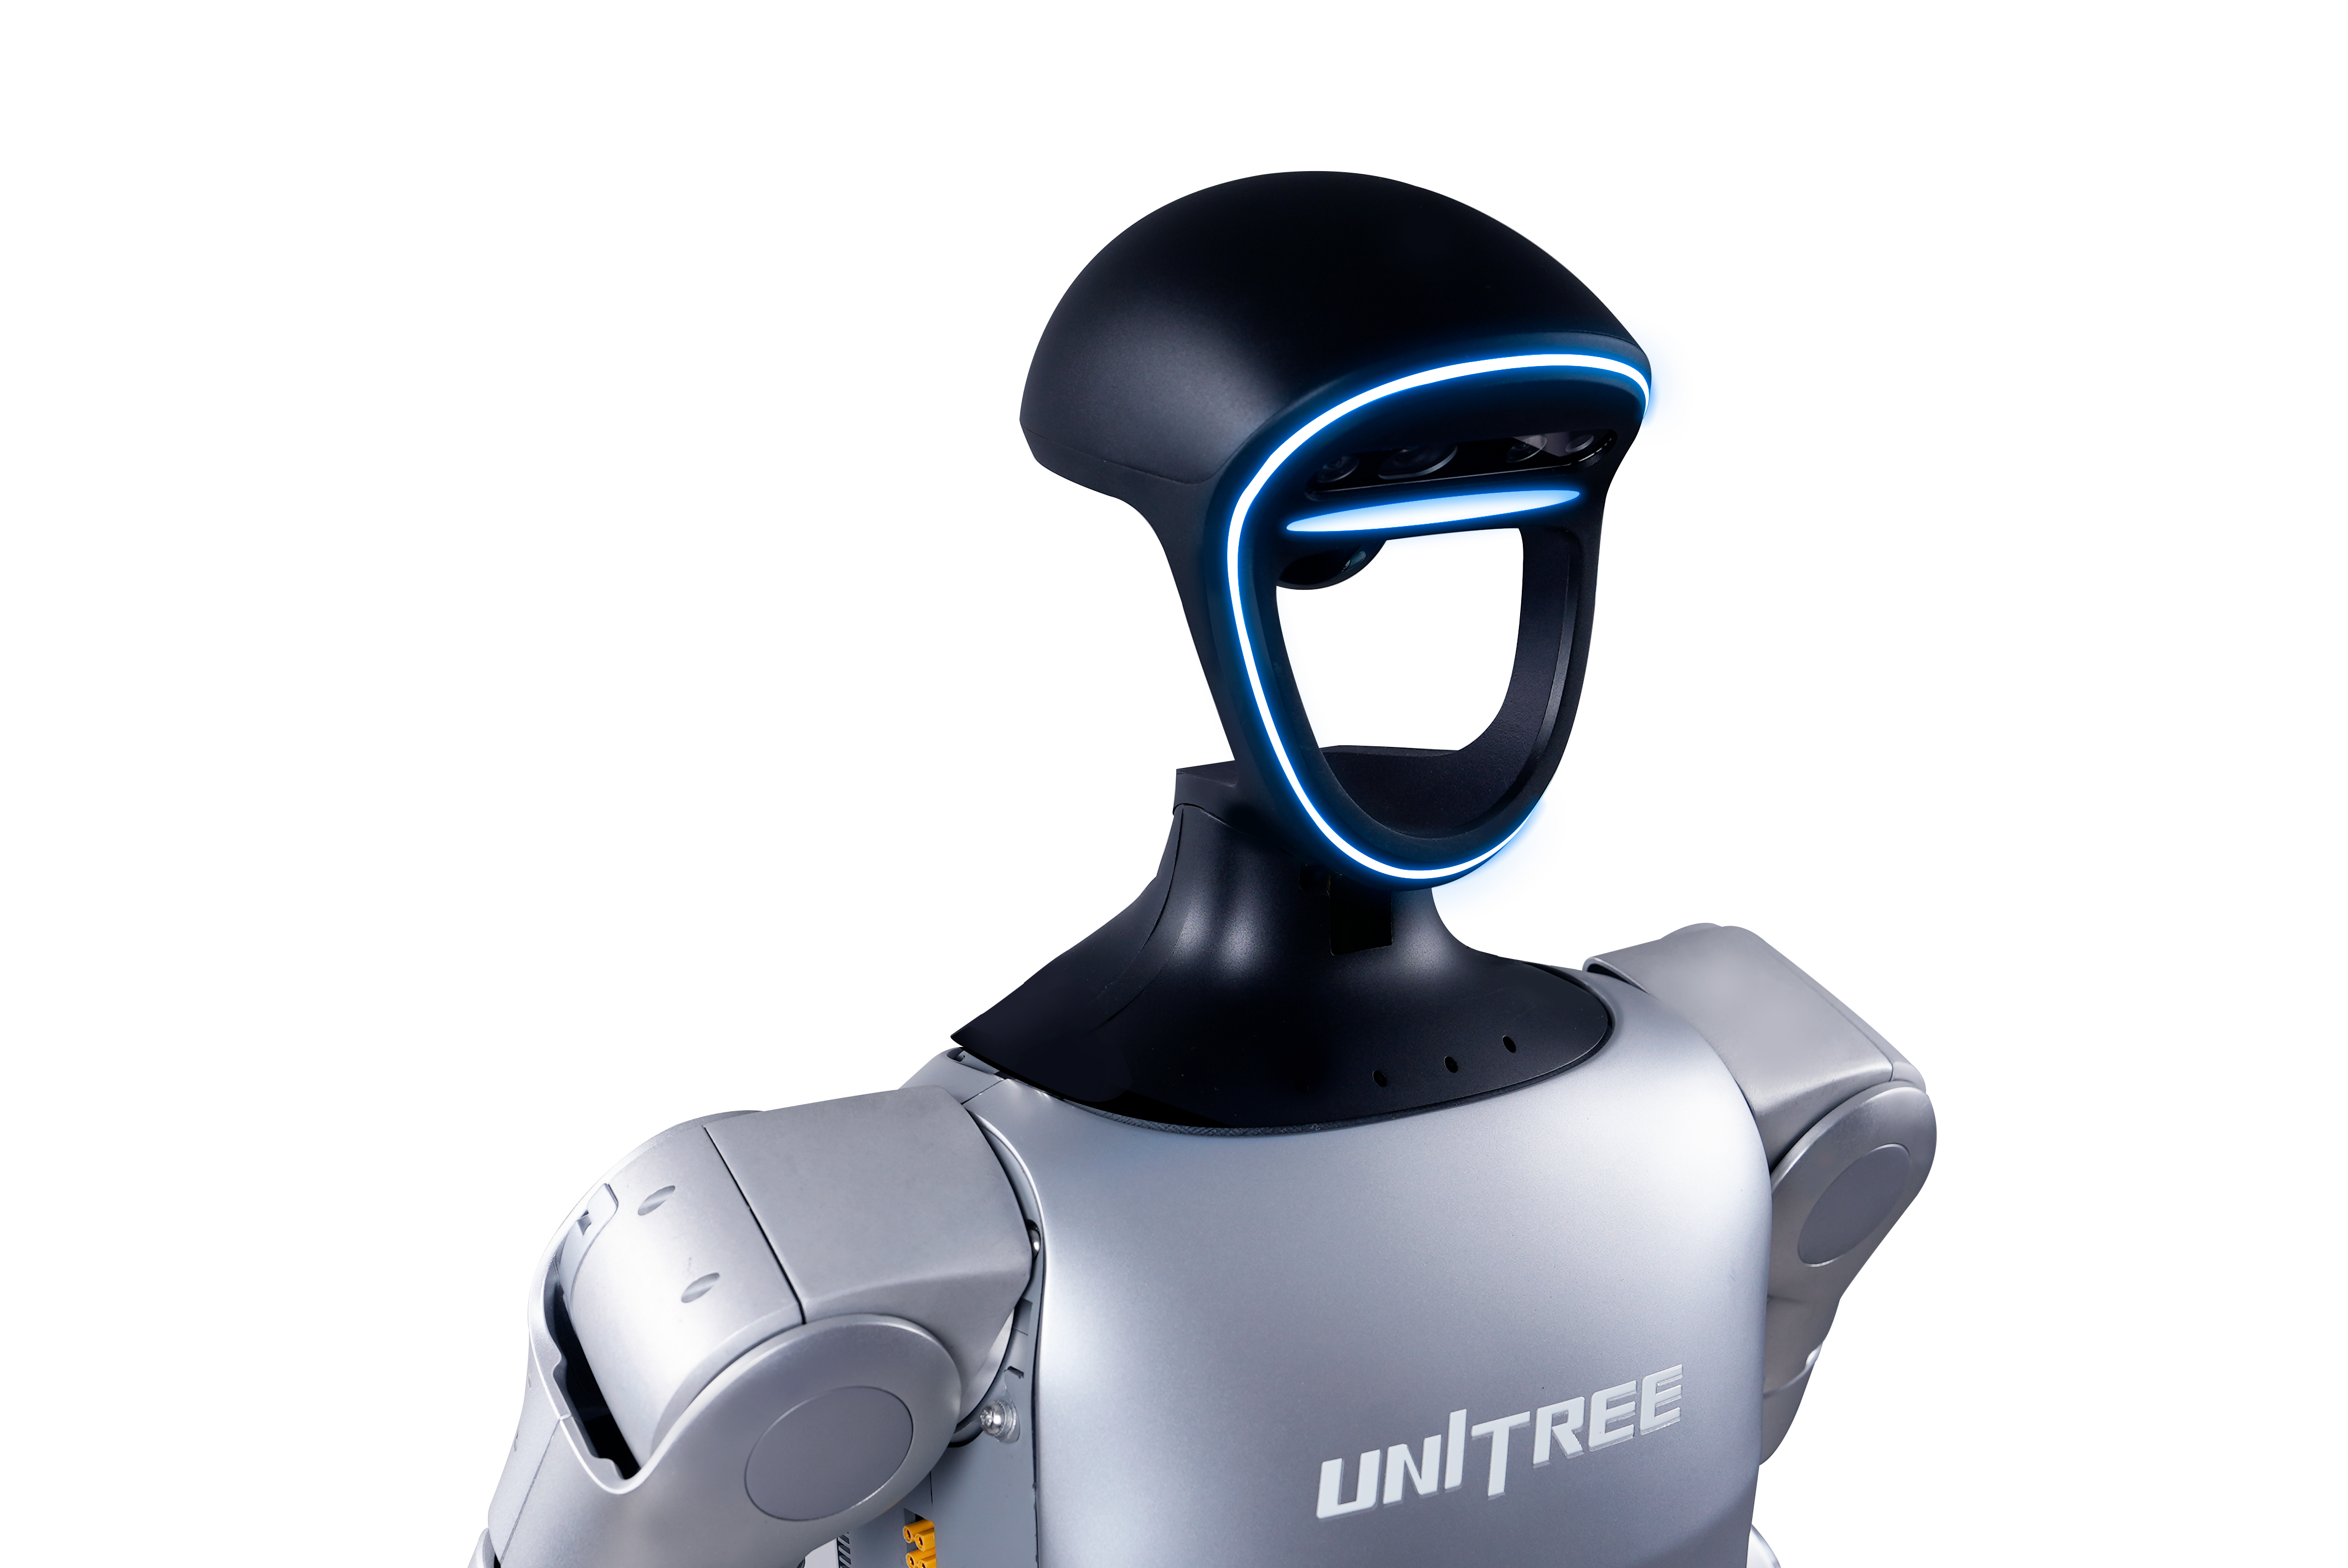
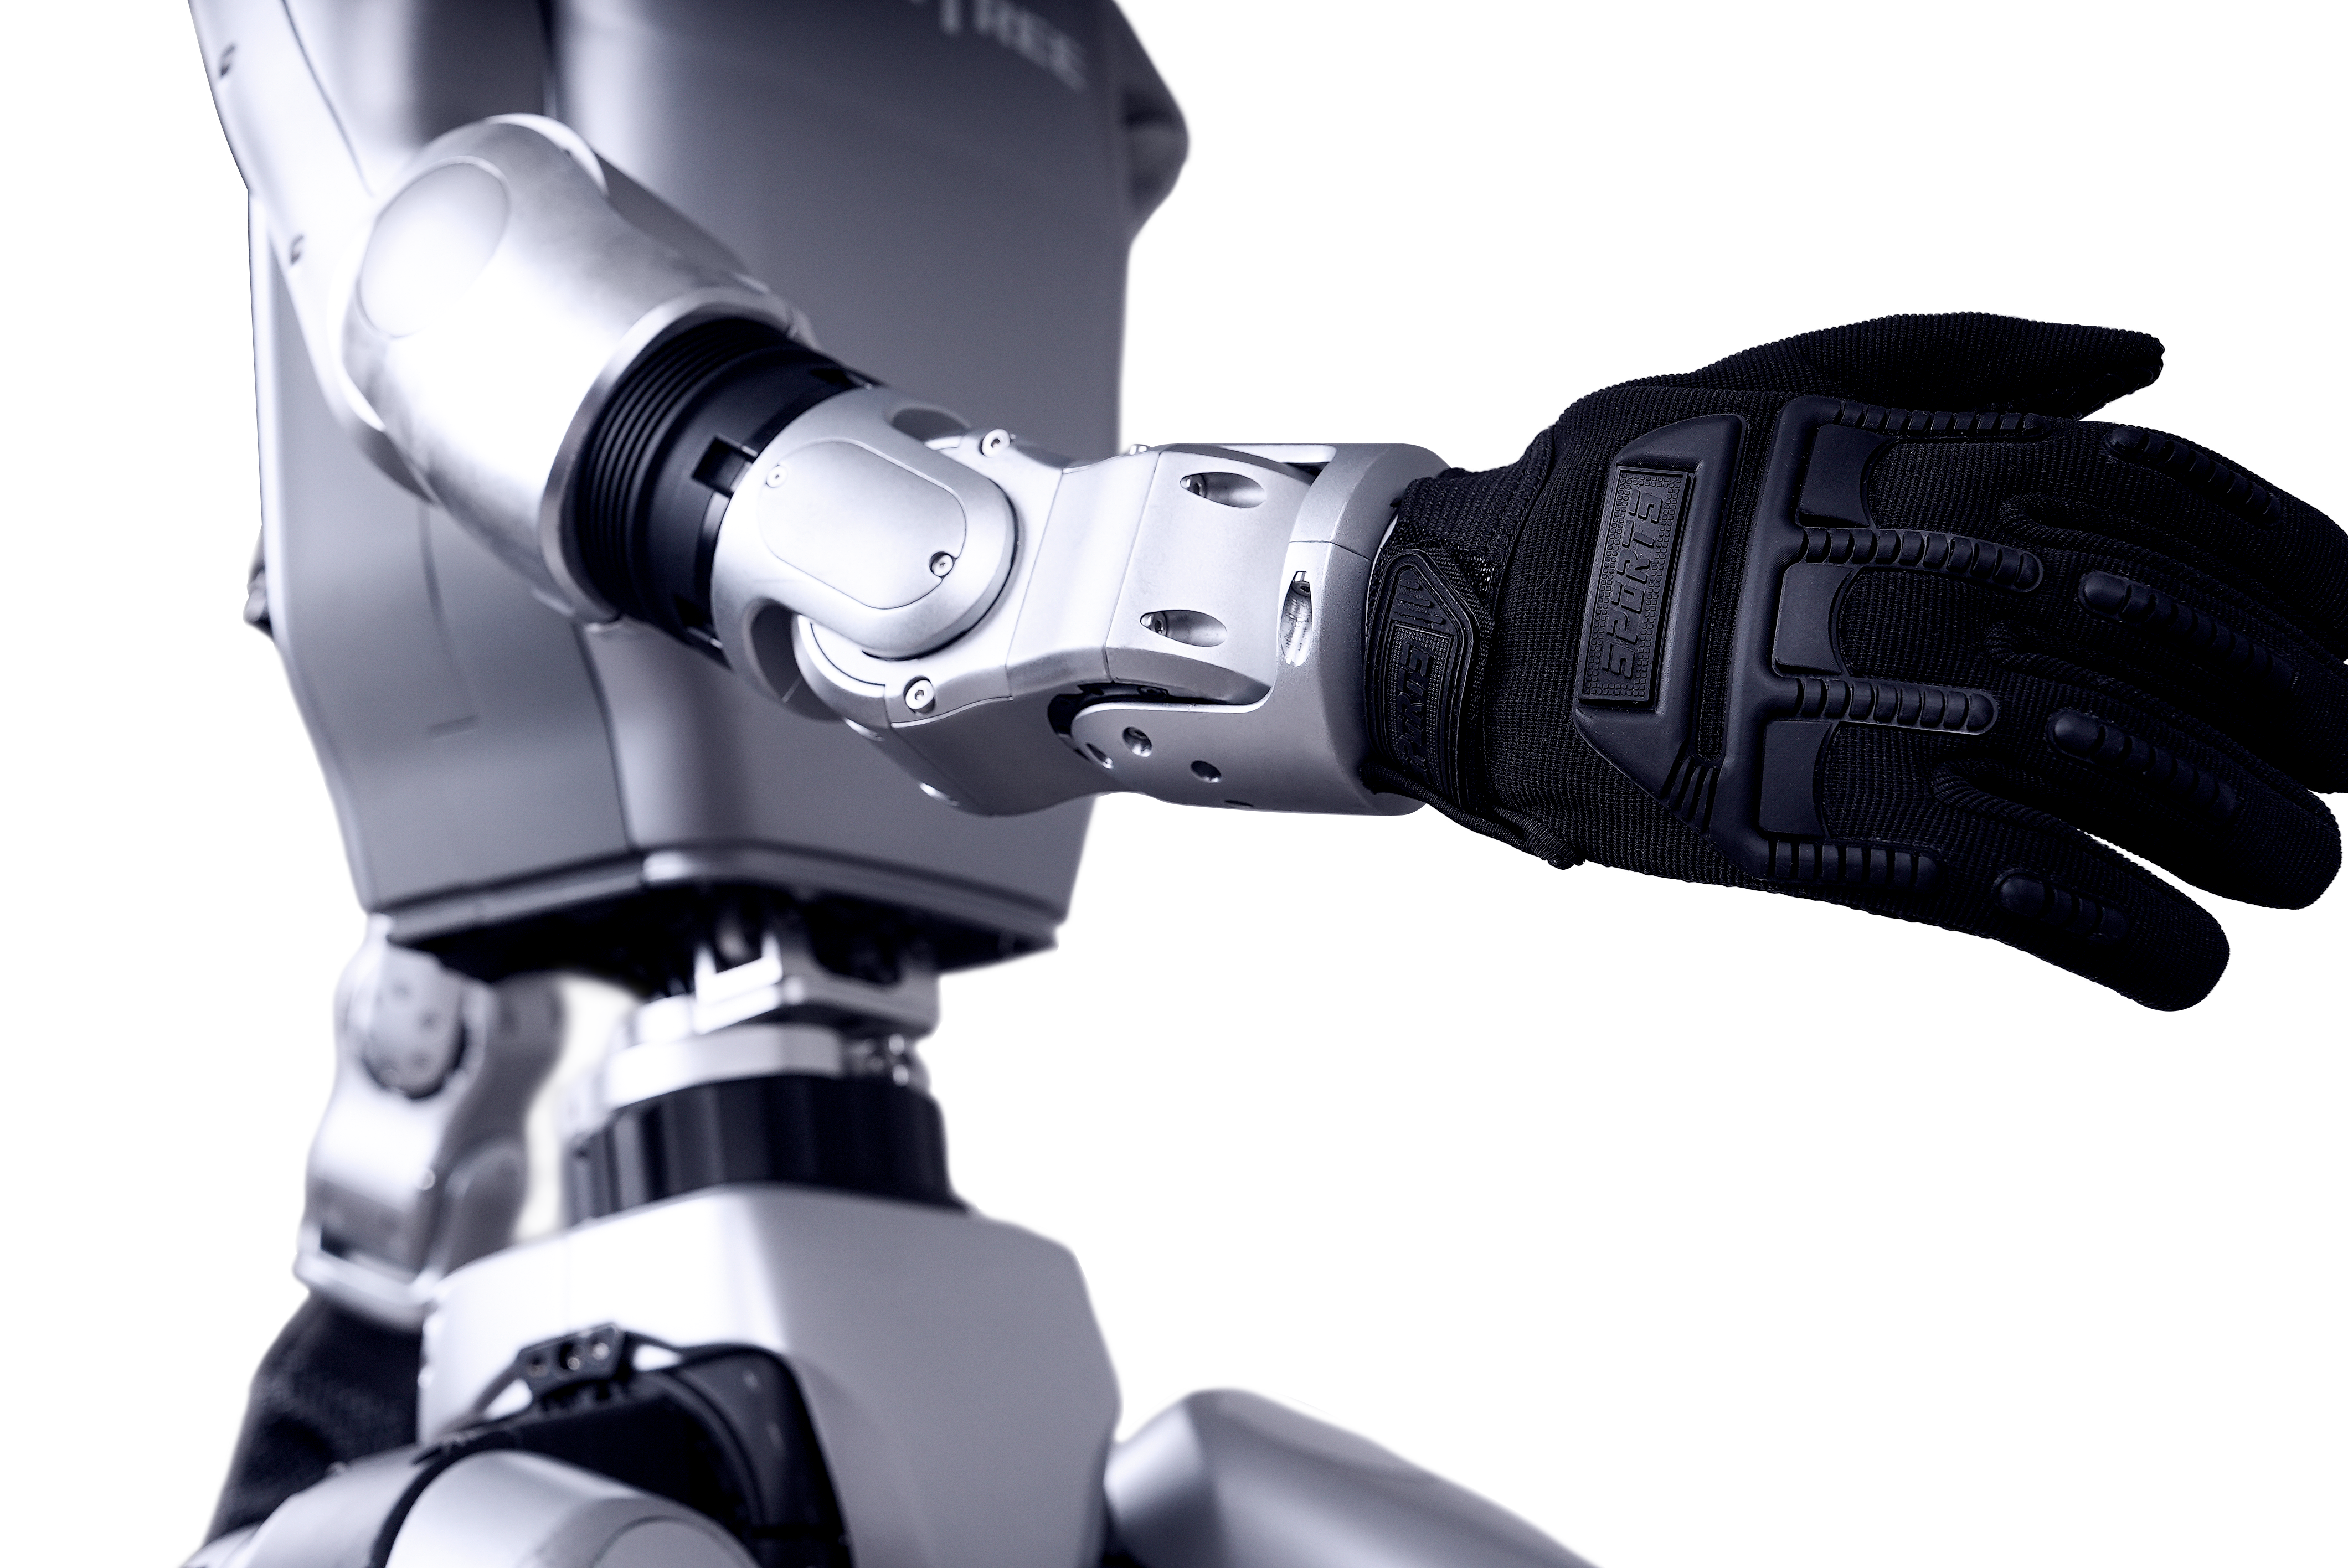
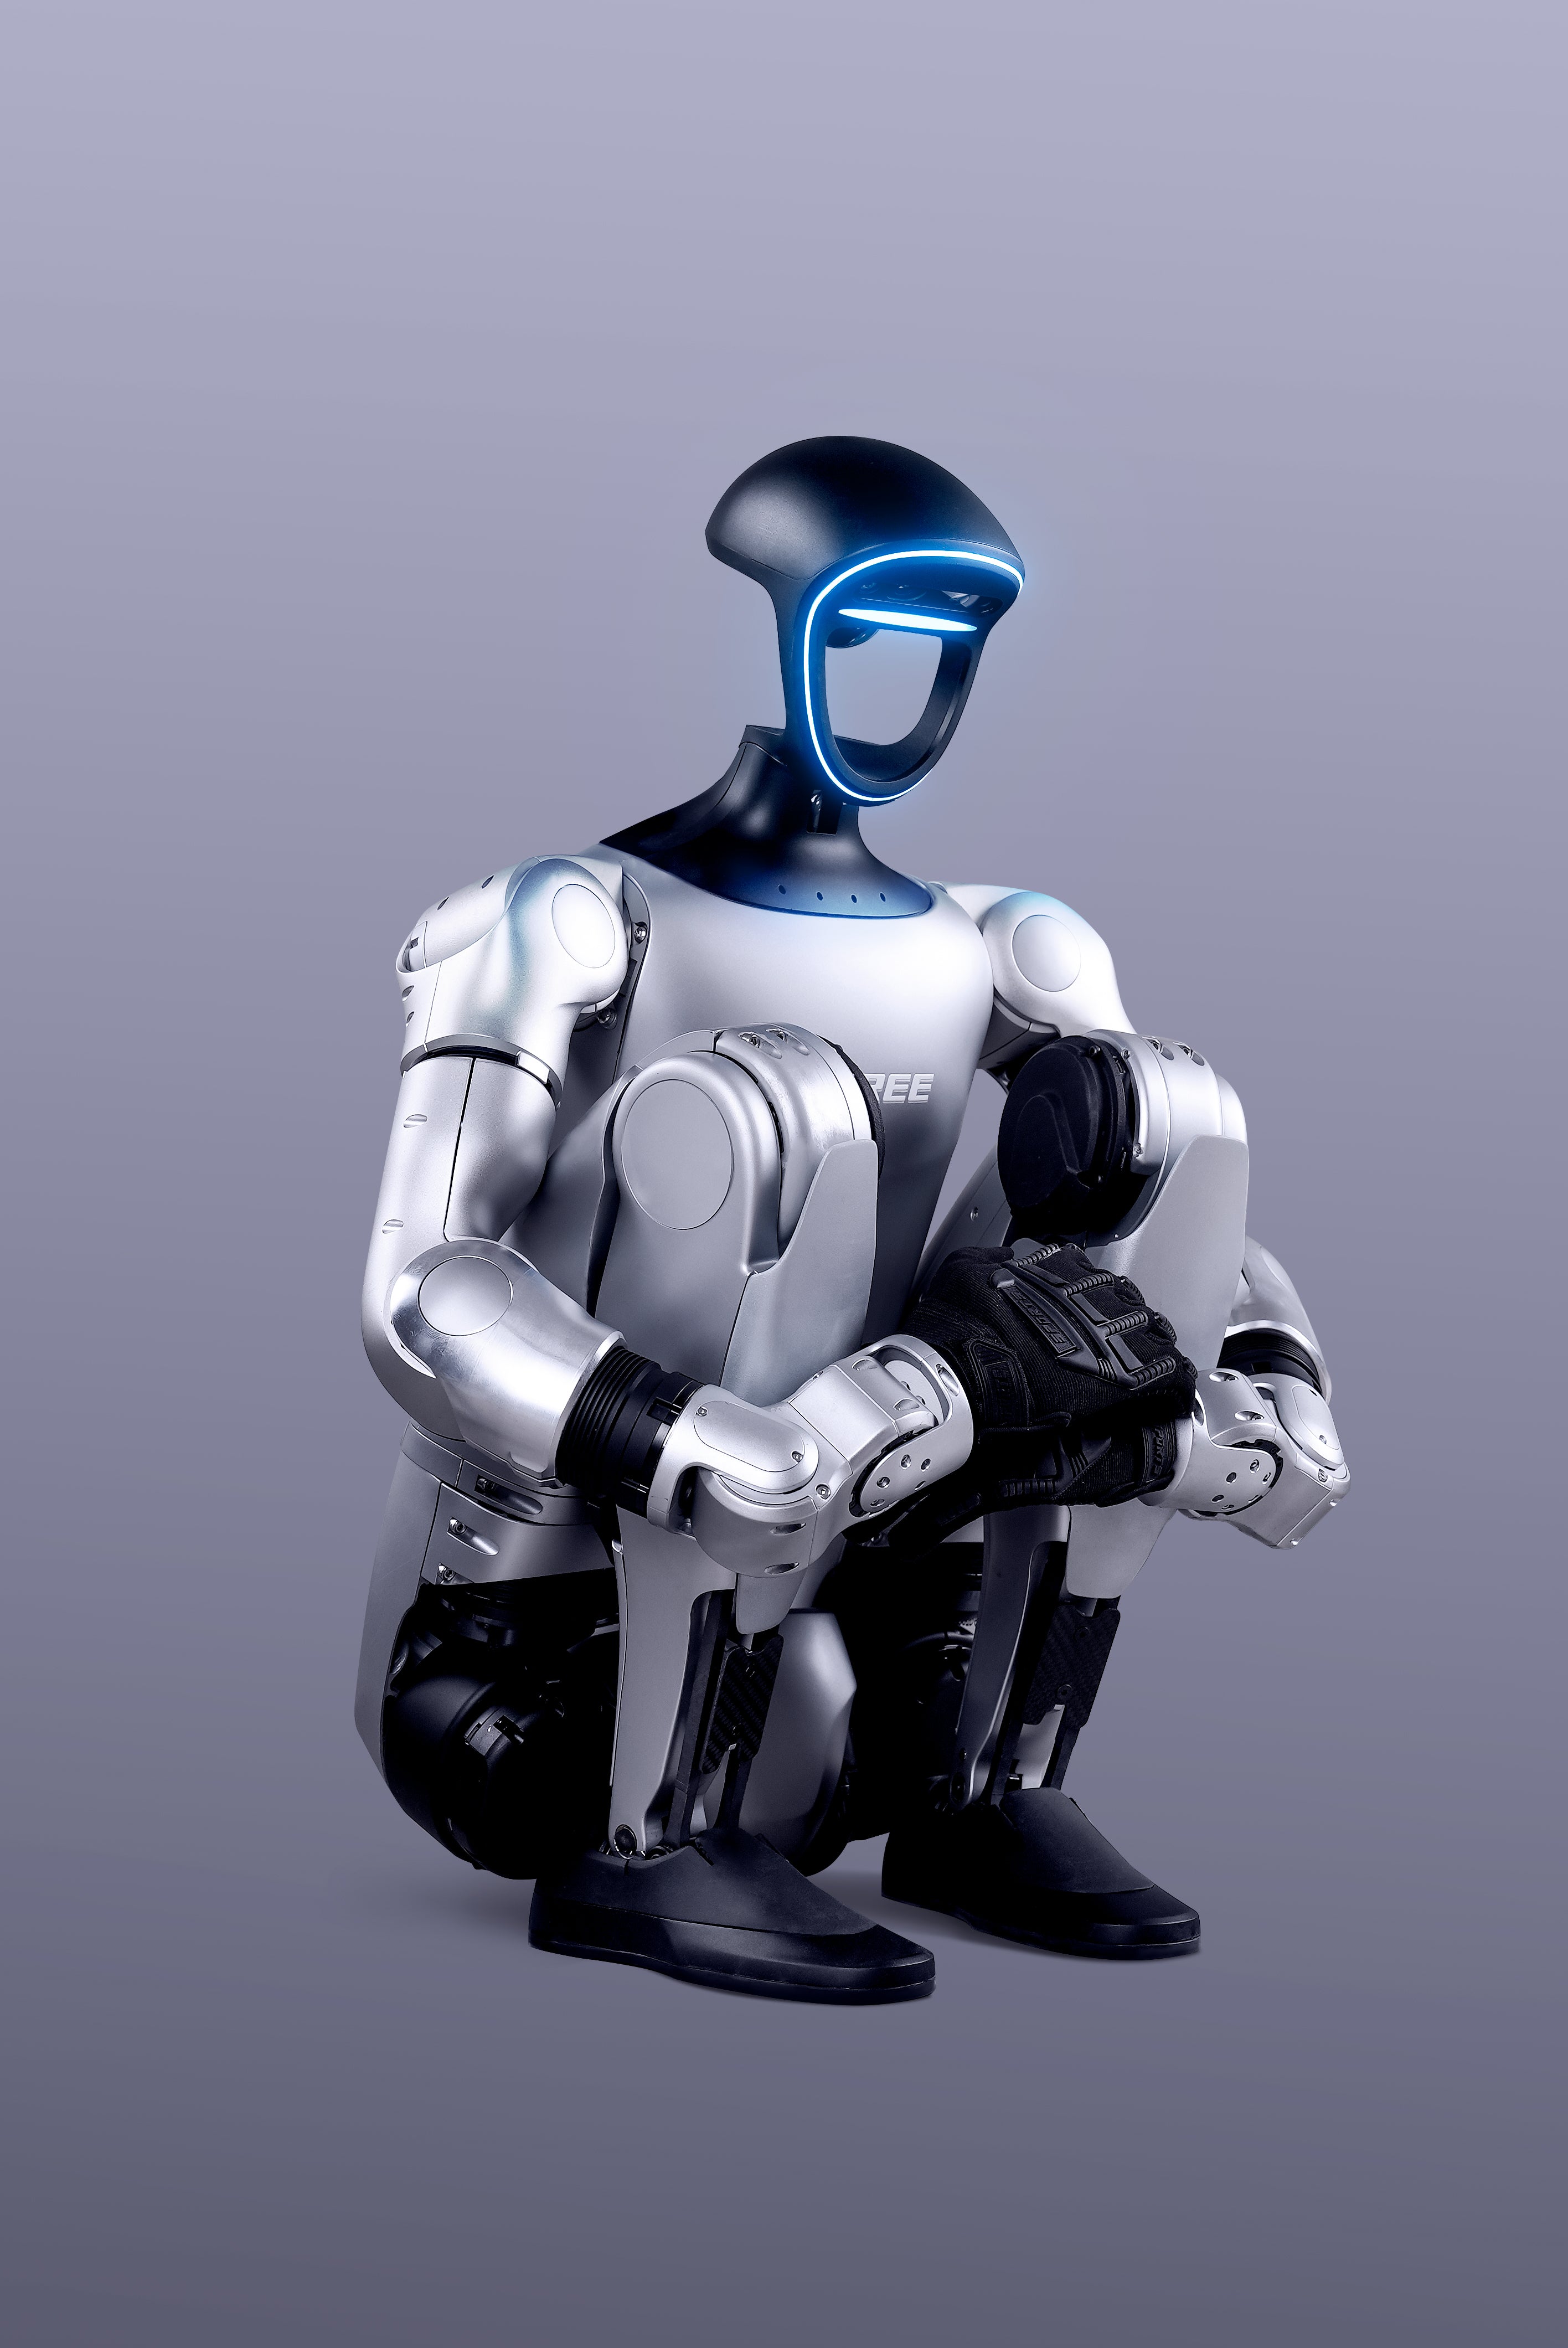
Secondary development
Degrees of freedom
Onboard AI compute
LIVOX MID360 standard
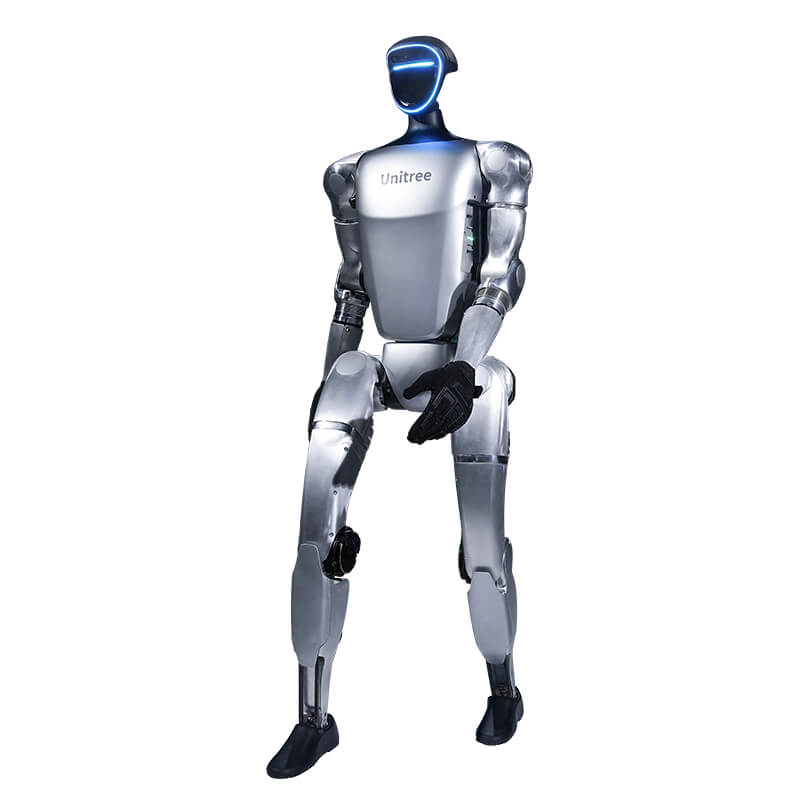
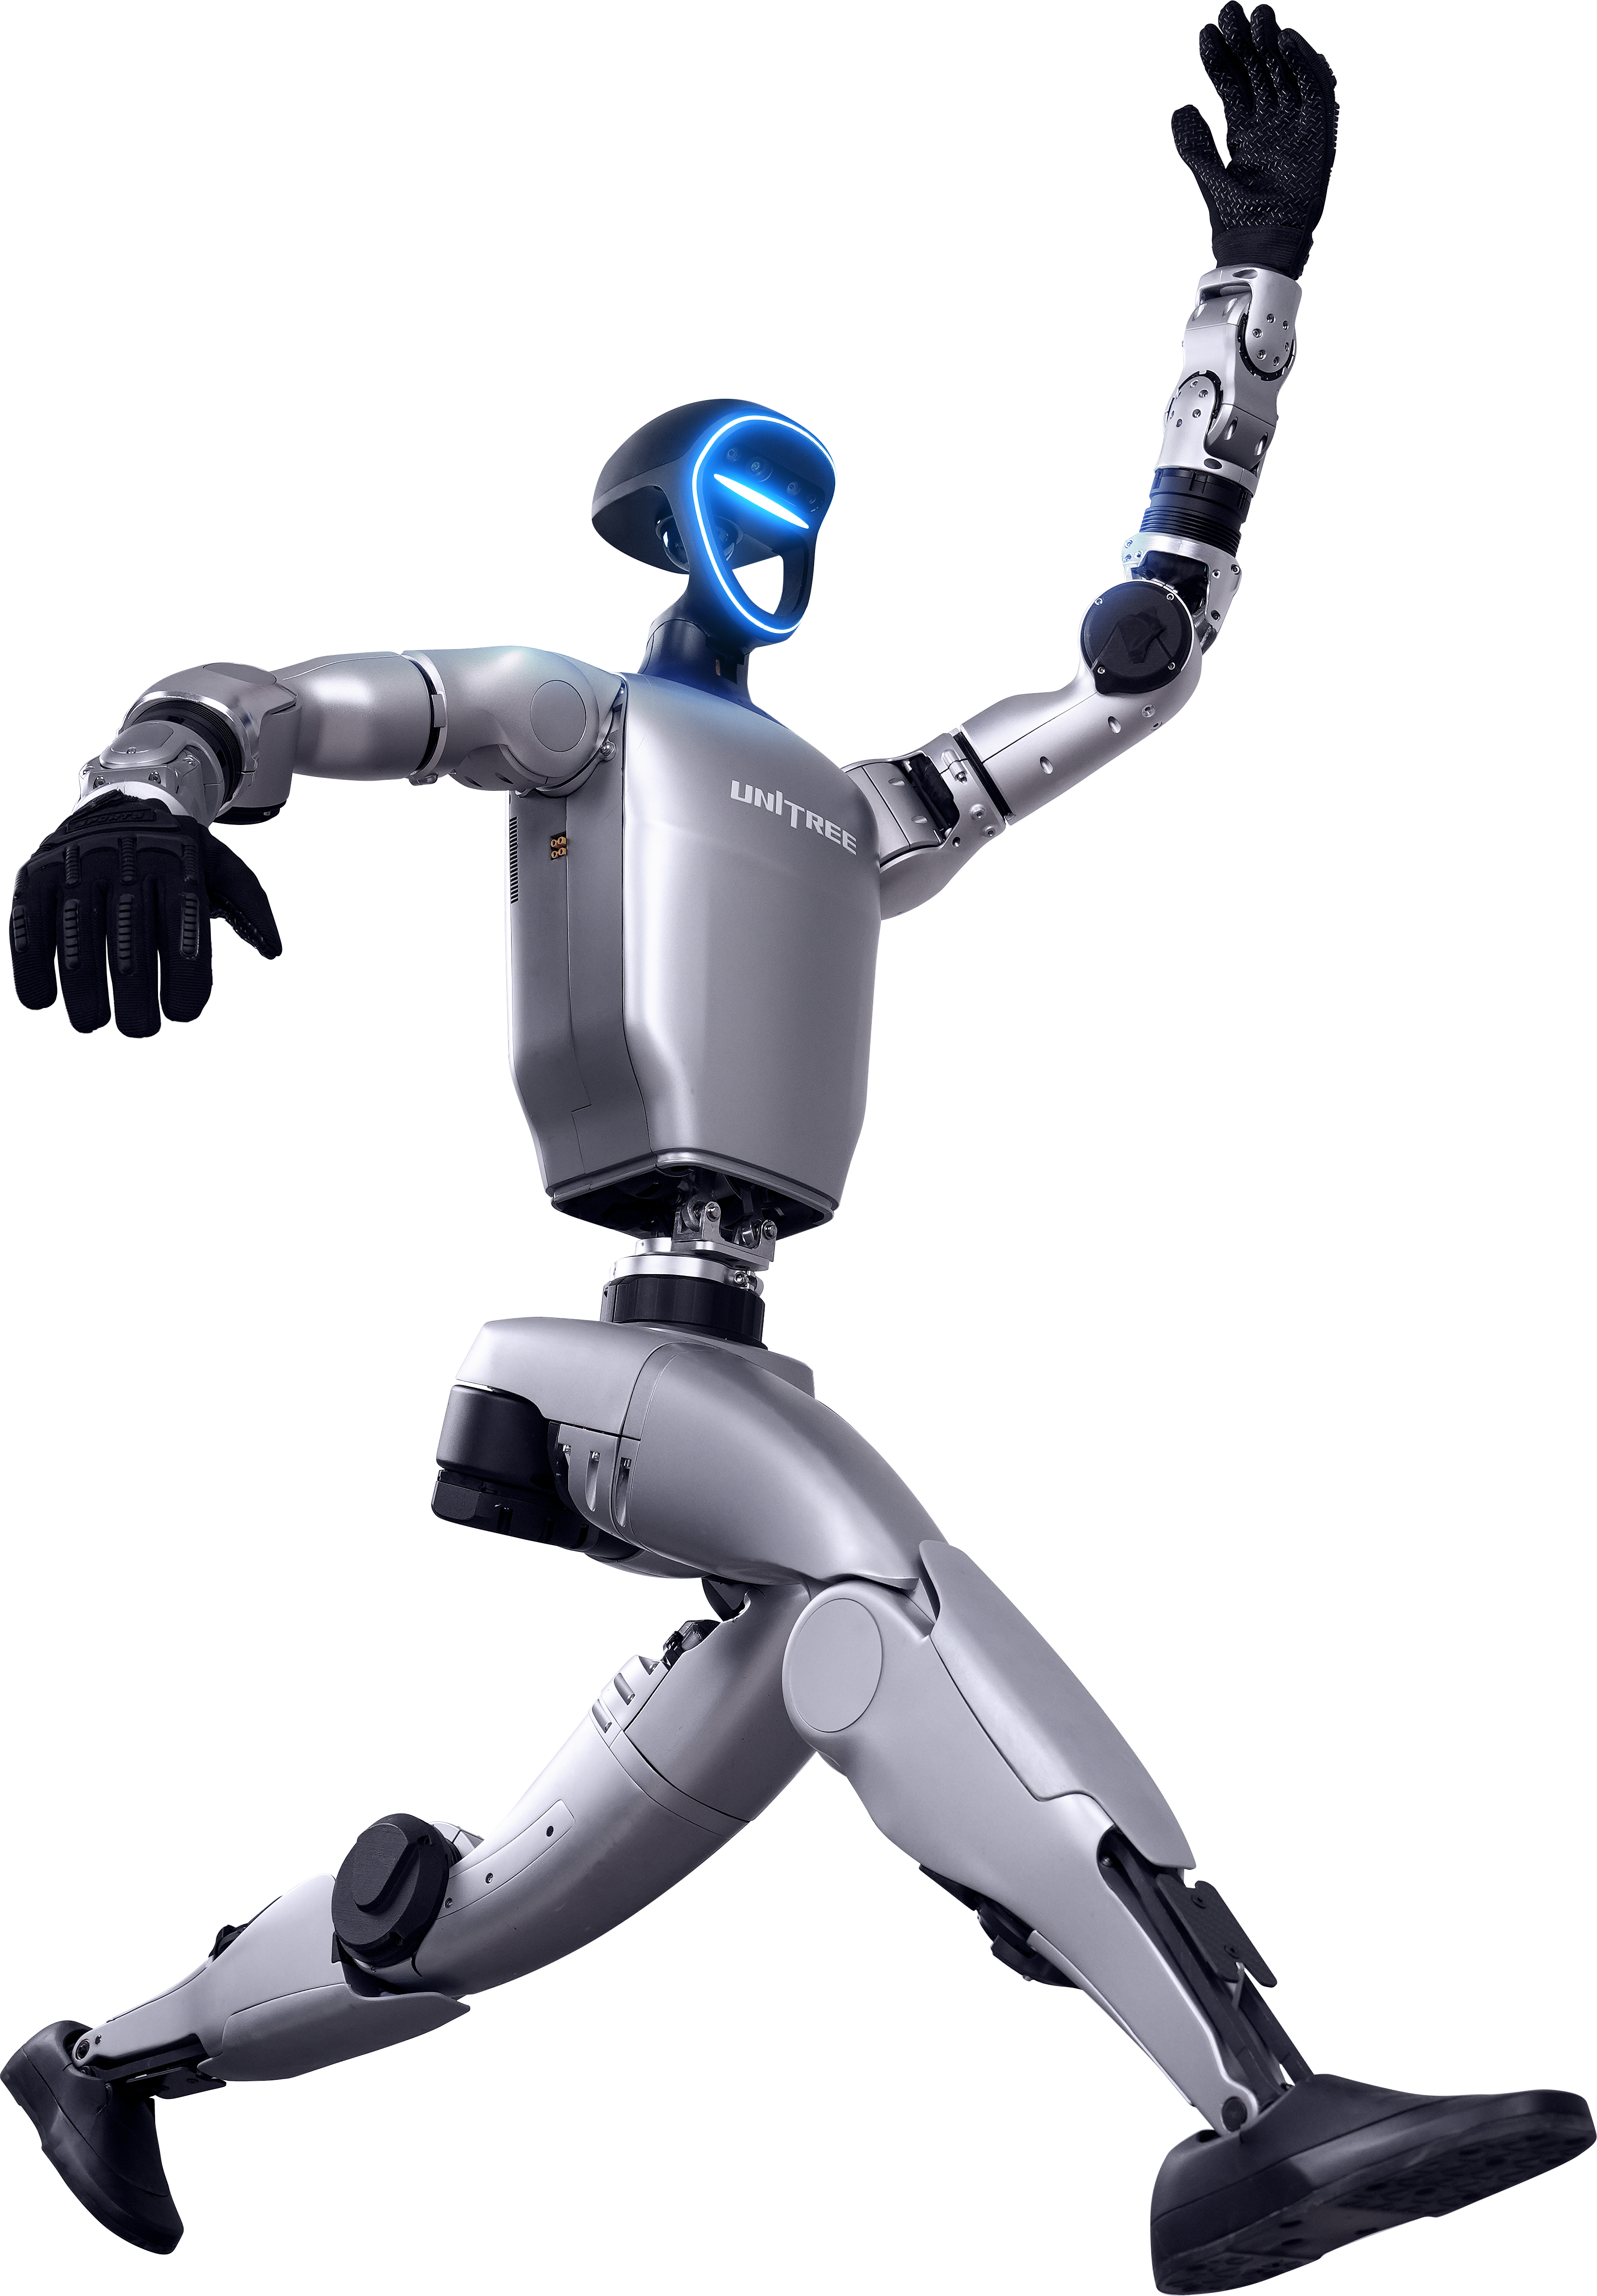
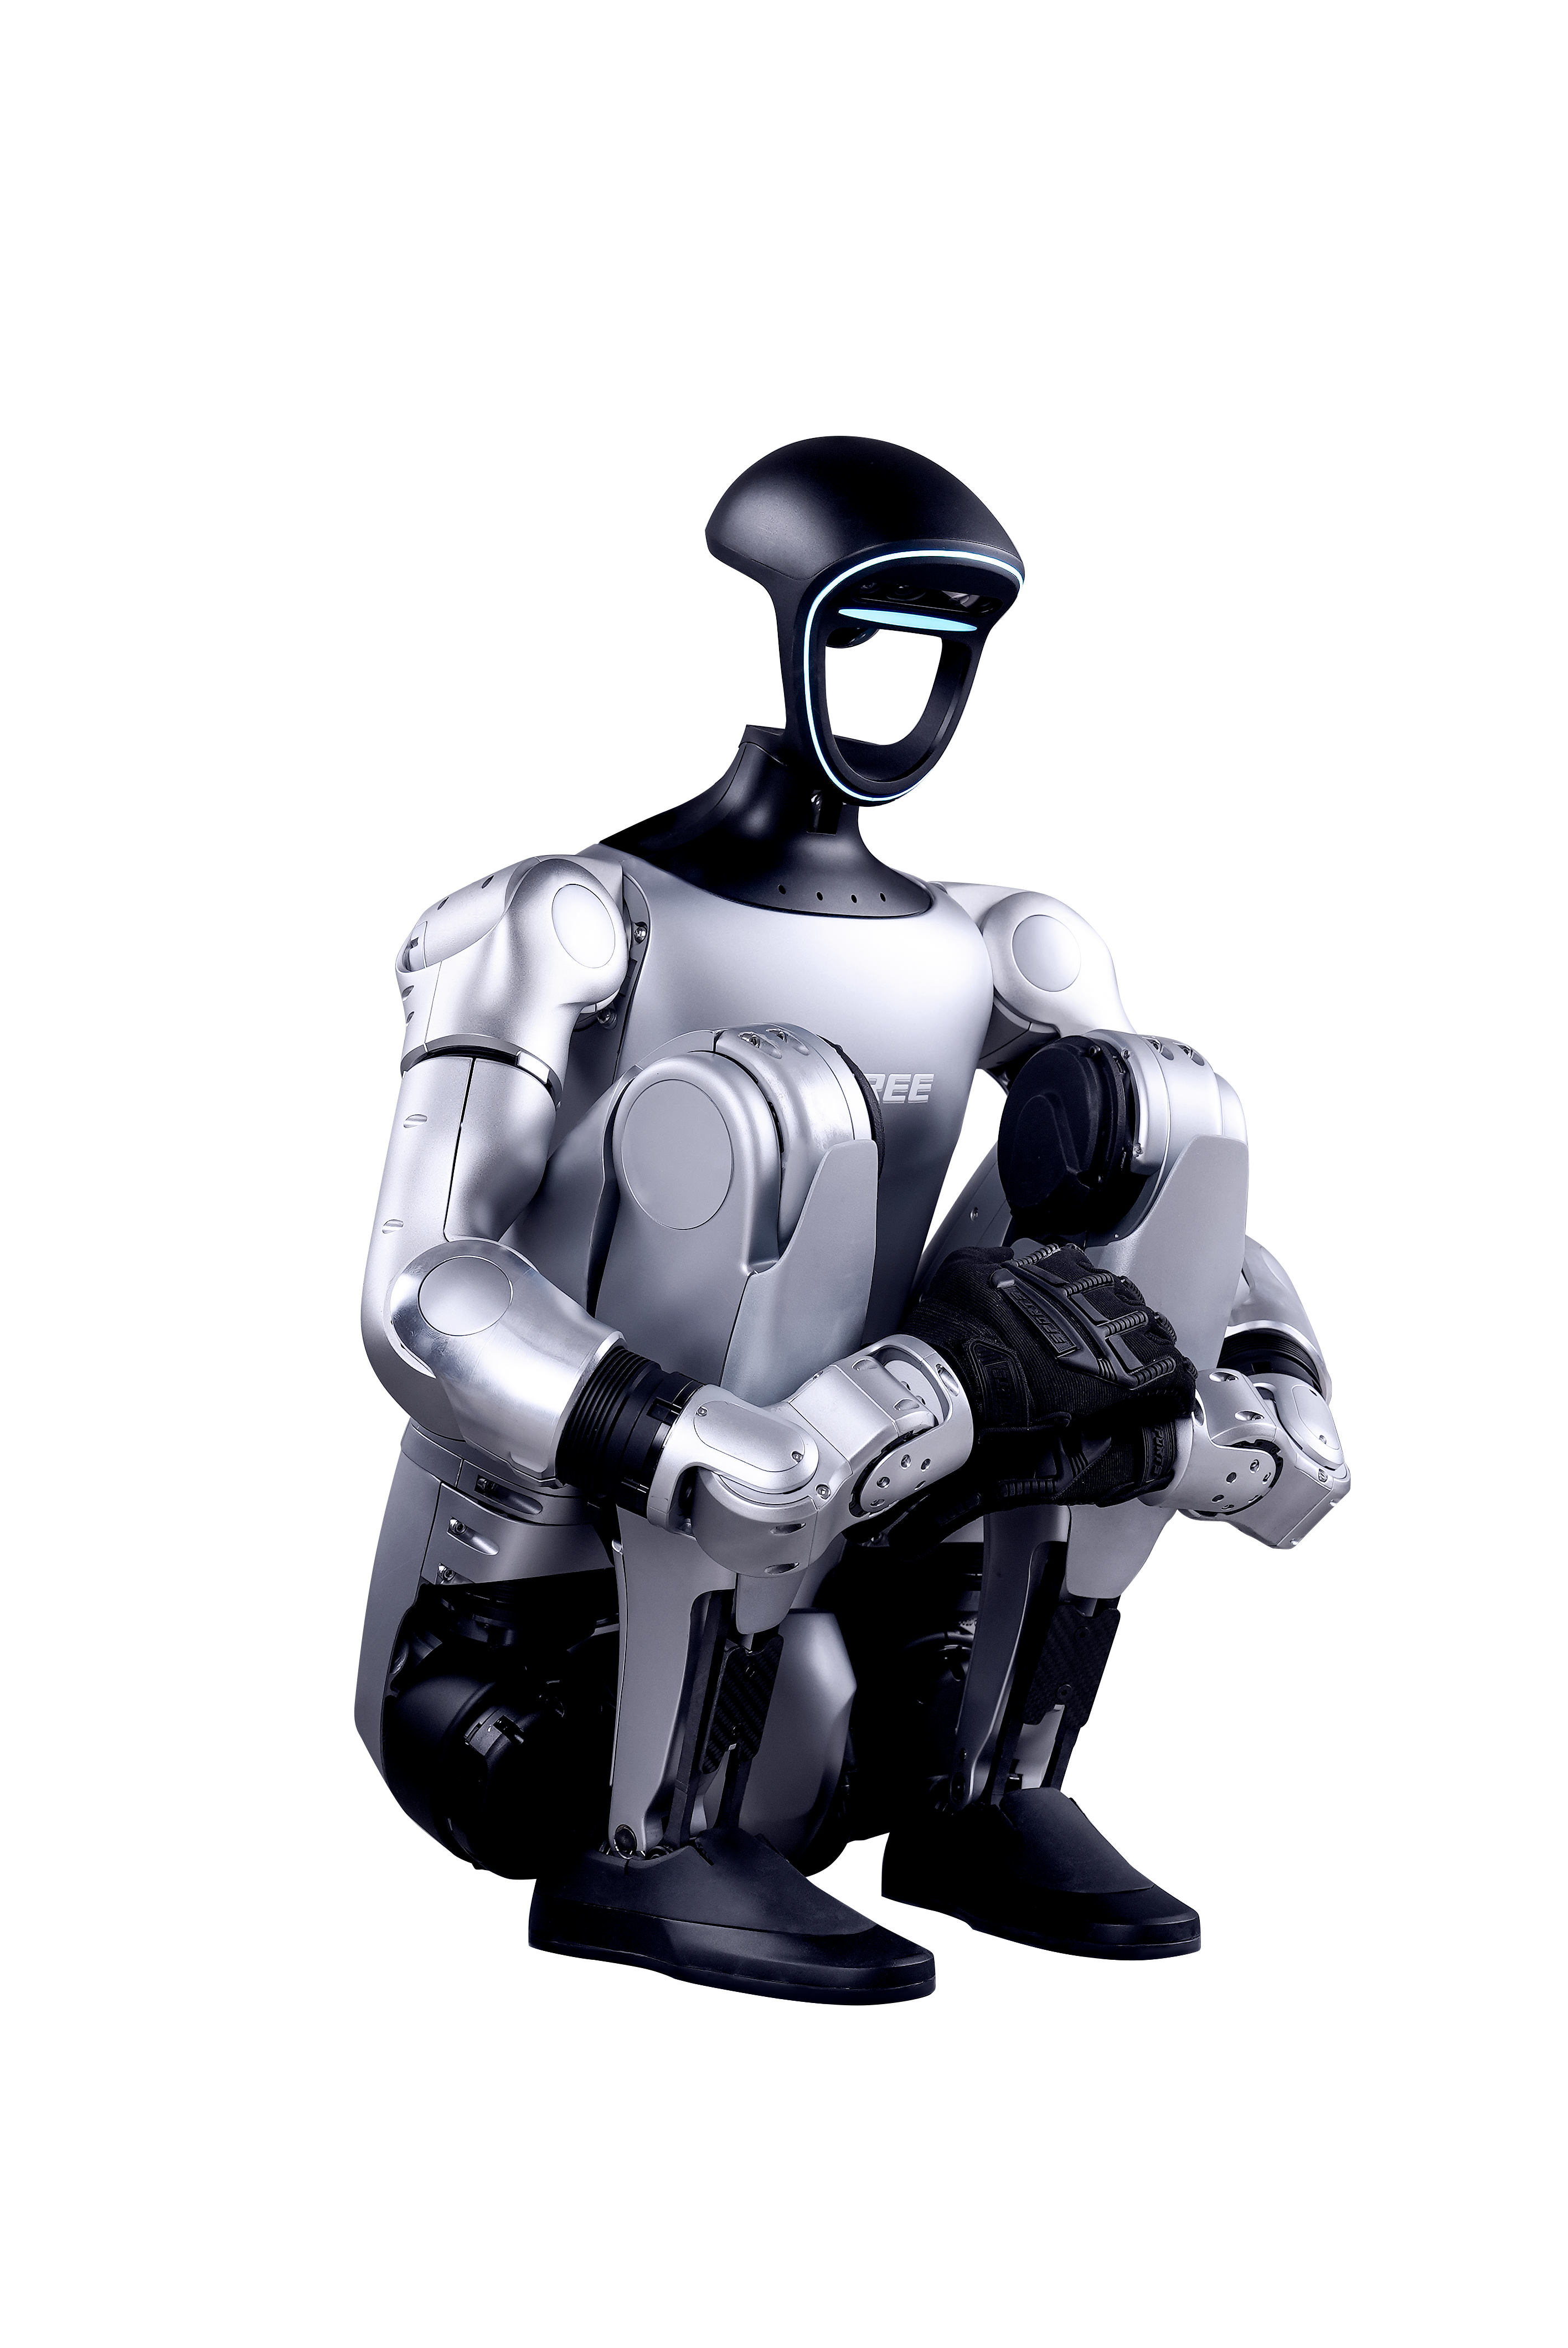
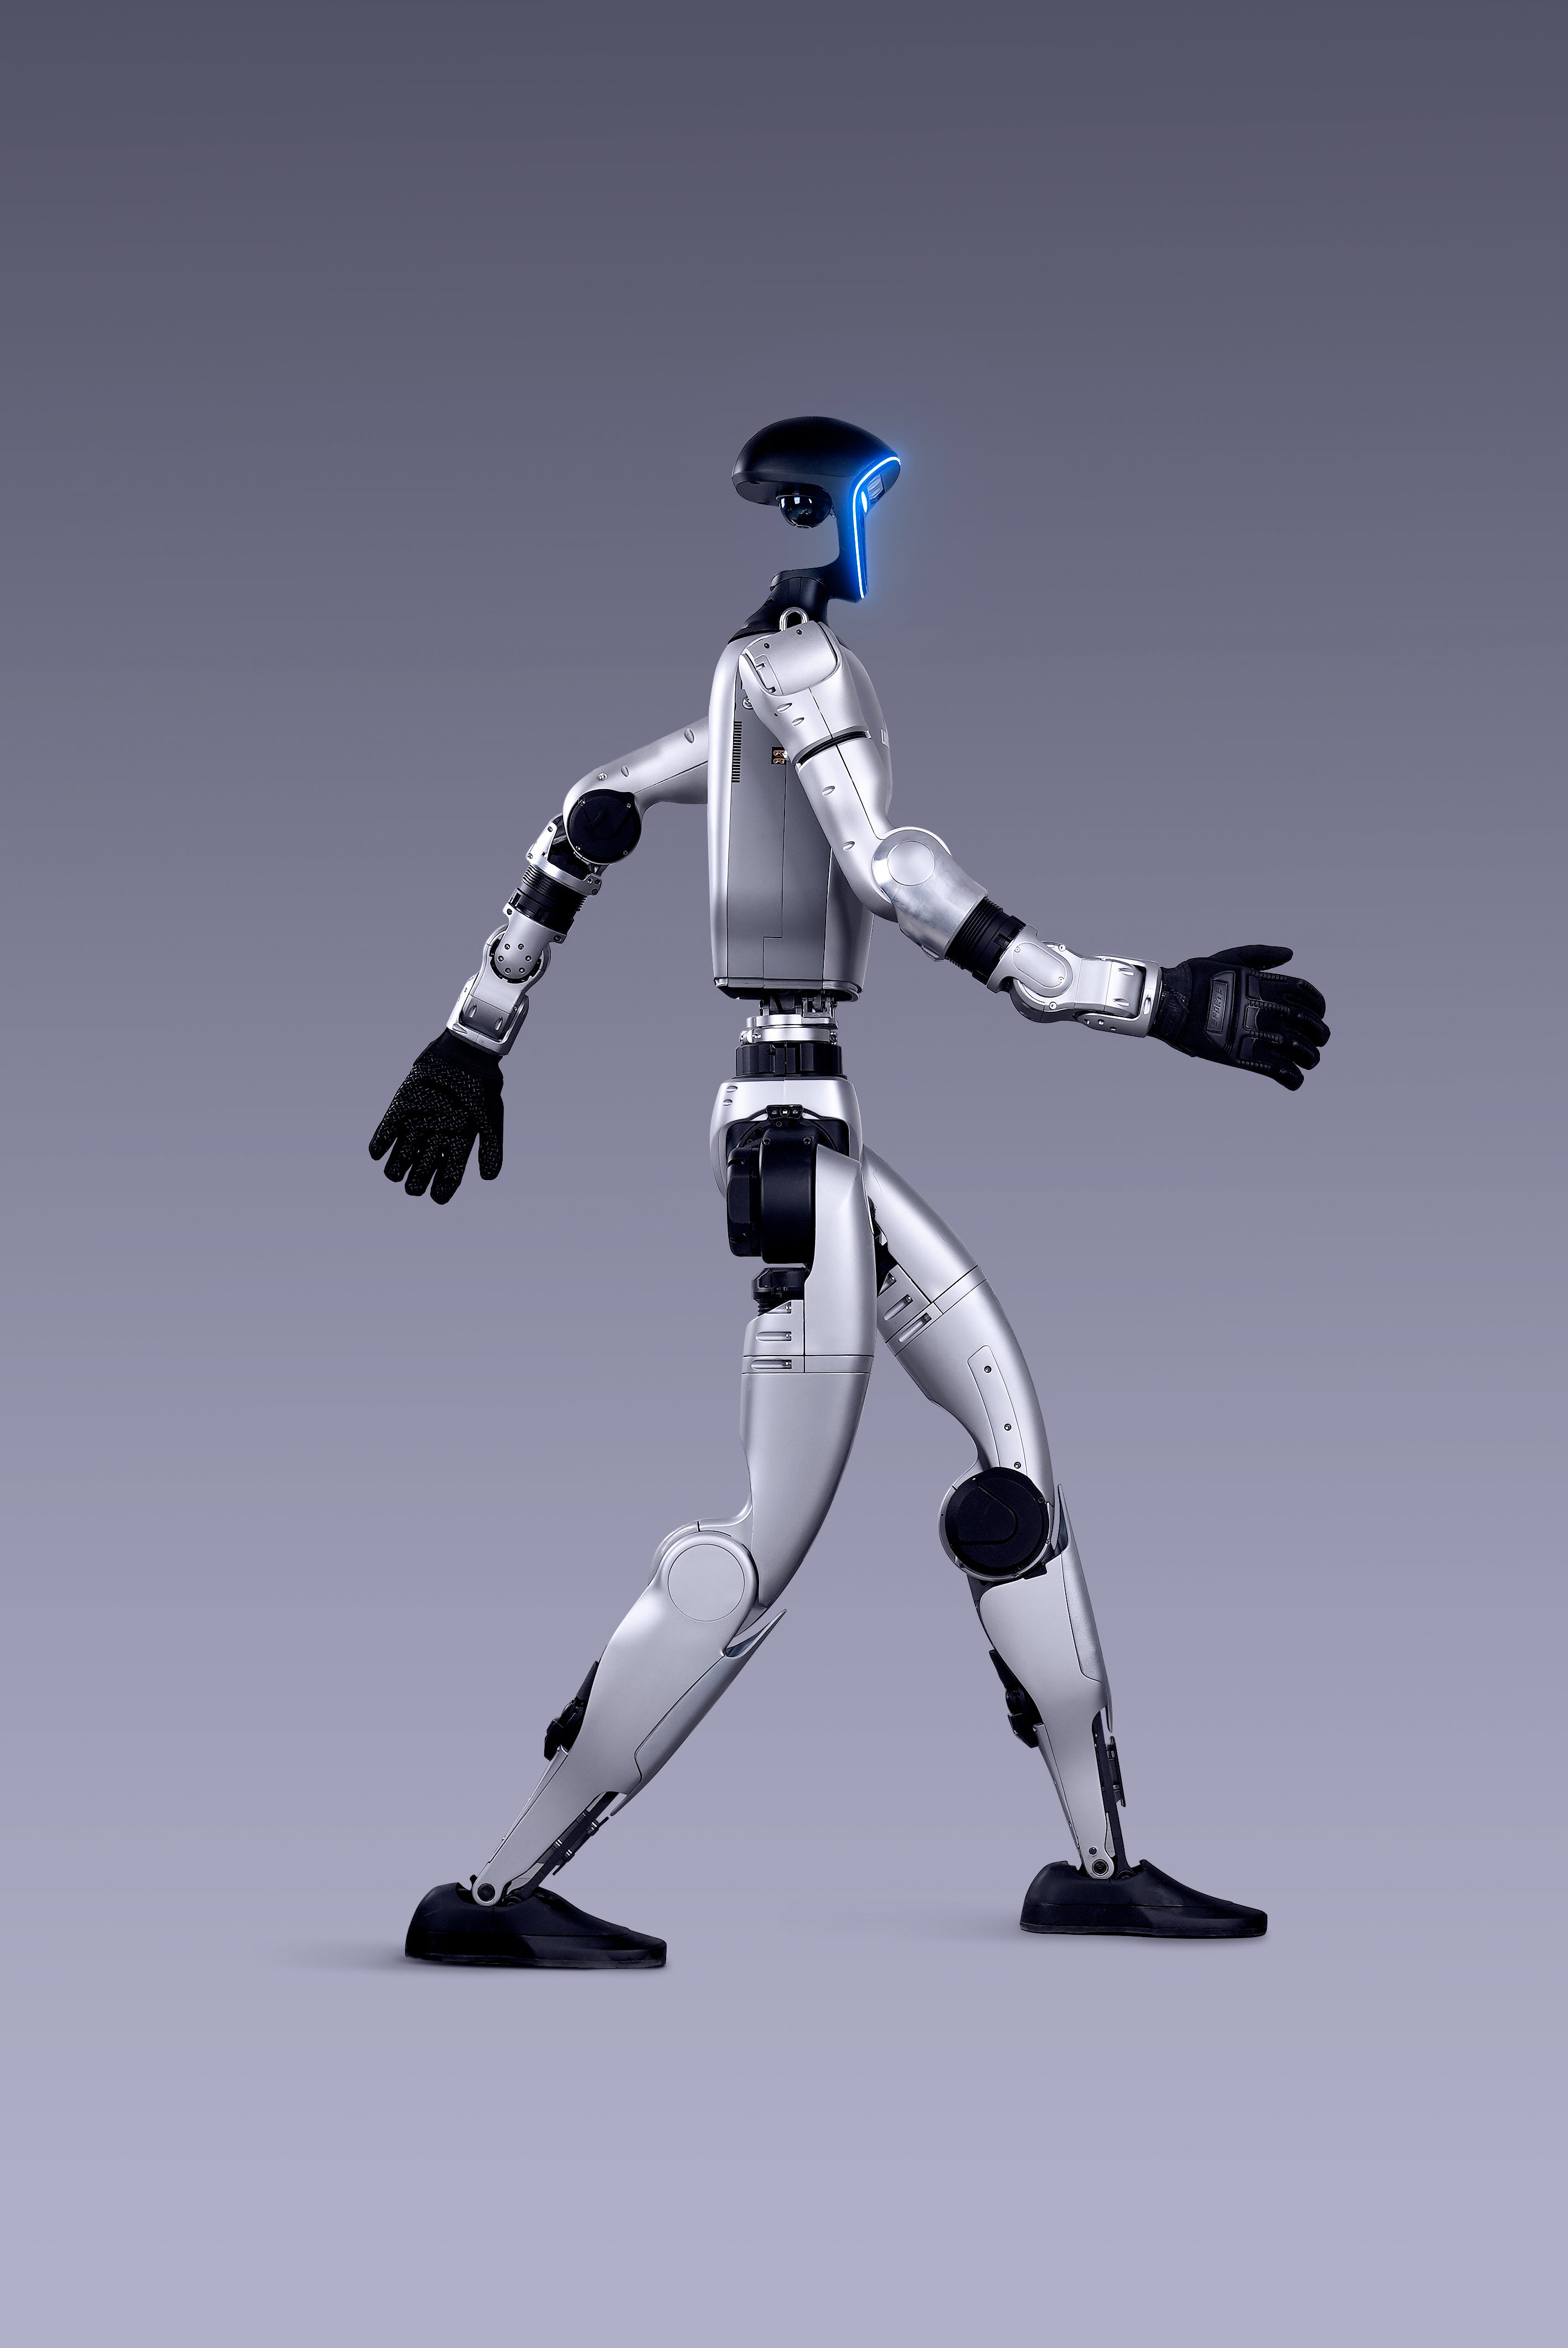
Standing height
Total weight
Battery runtime
Dynamic locomotion


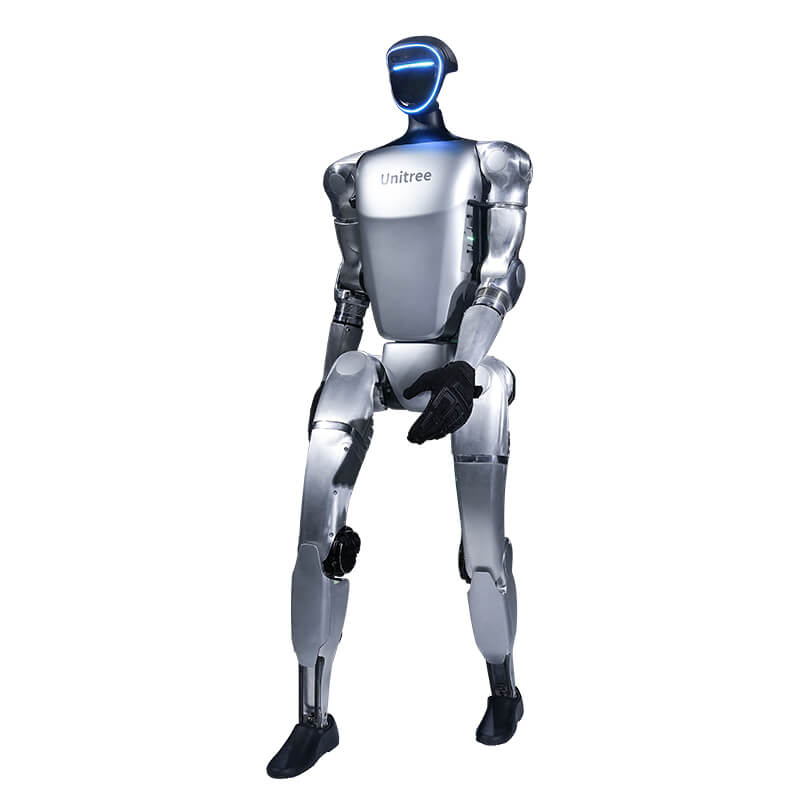
Degrees of freedom
MID360 + depth camera
Battery runtime
Weight with battery

Maximize Yield. Minimize Labor.
Cover more ground with precision agriculture technology.
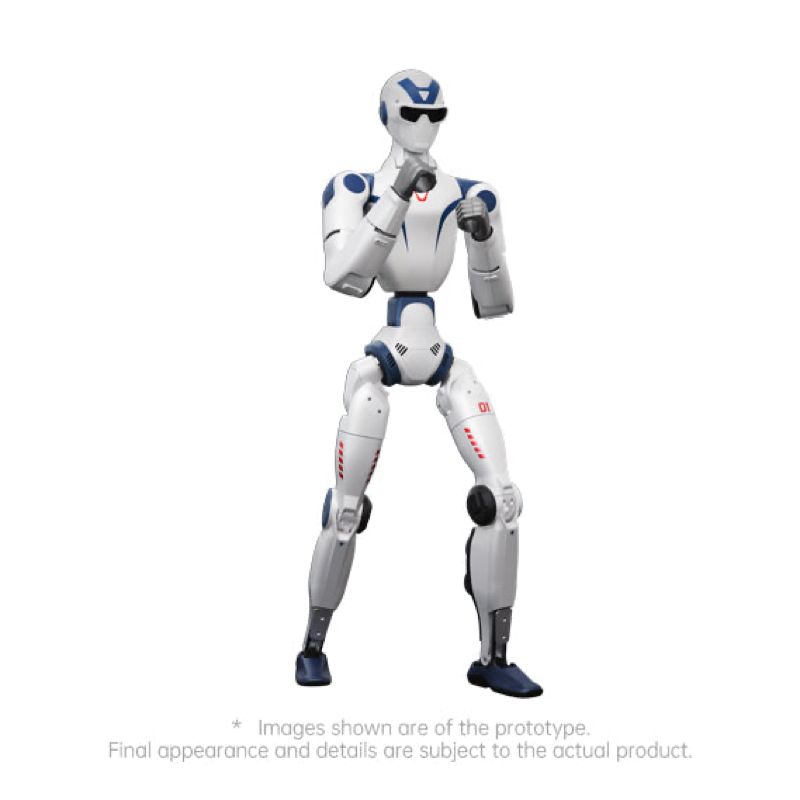


Secondary development
Degrees of freedom
Optional Orin compute
Depth camera
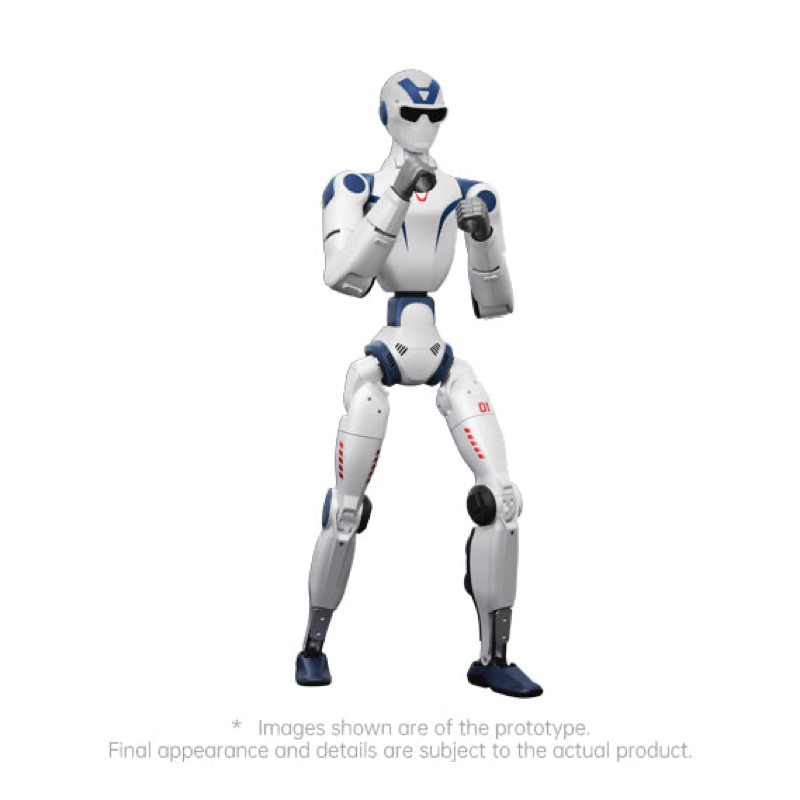


Degrees of freedom
Total weight
Standing height
Speech and vision
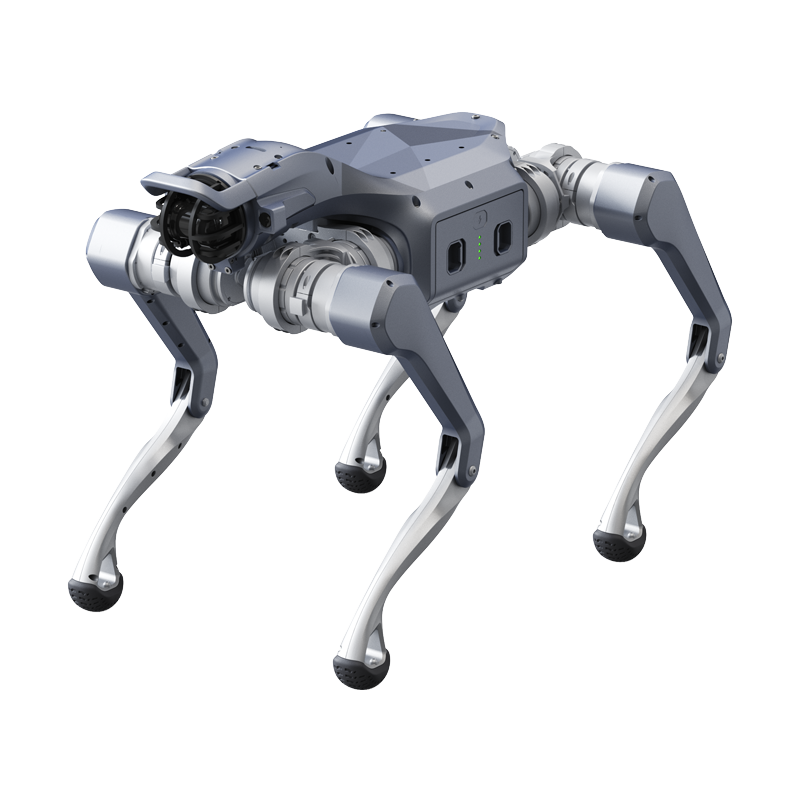
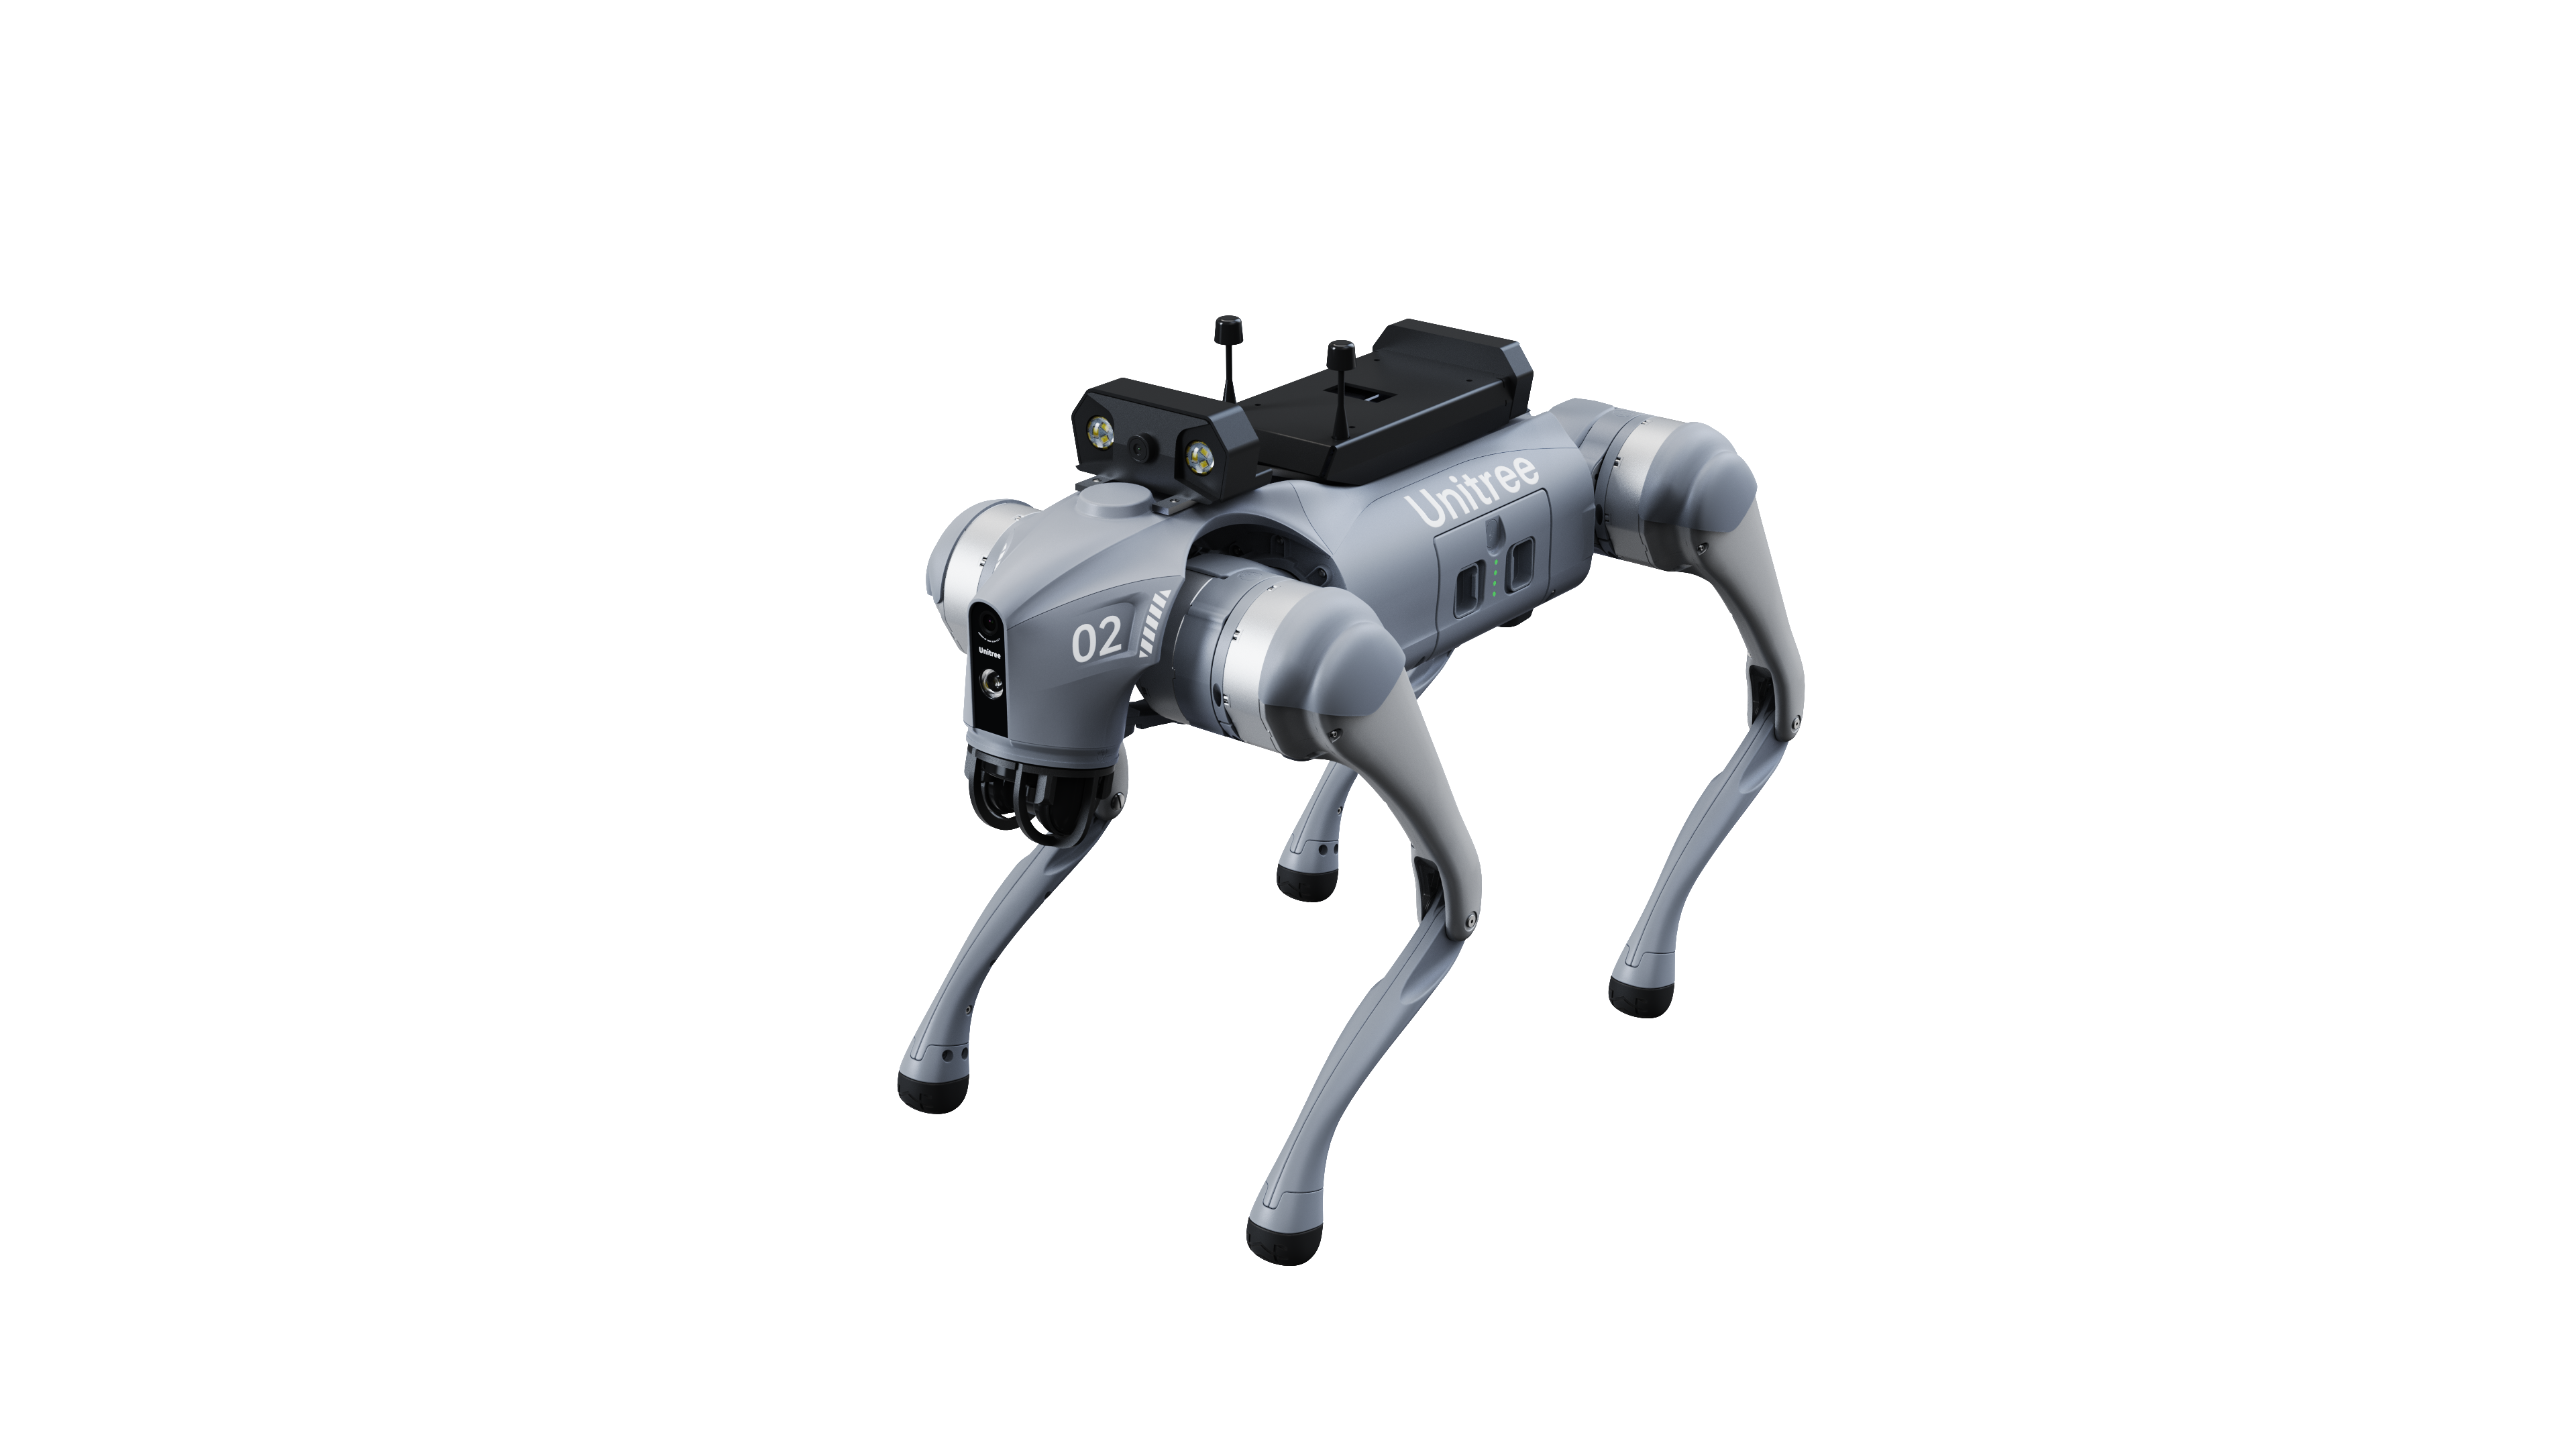
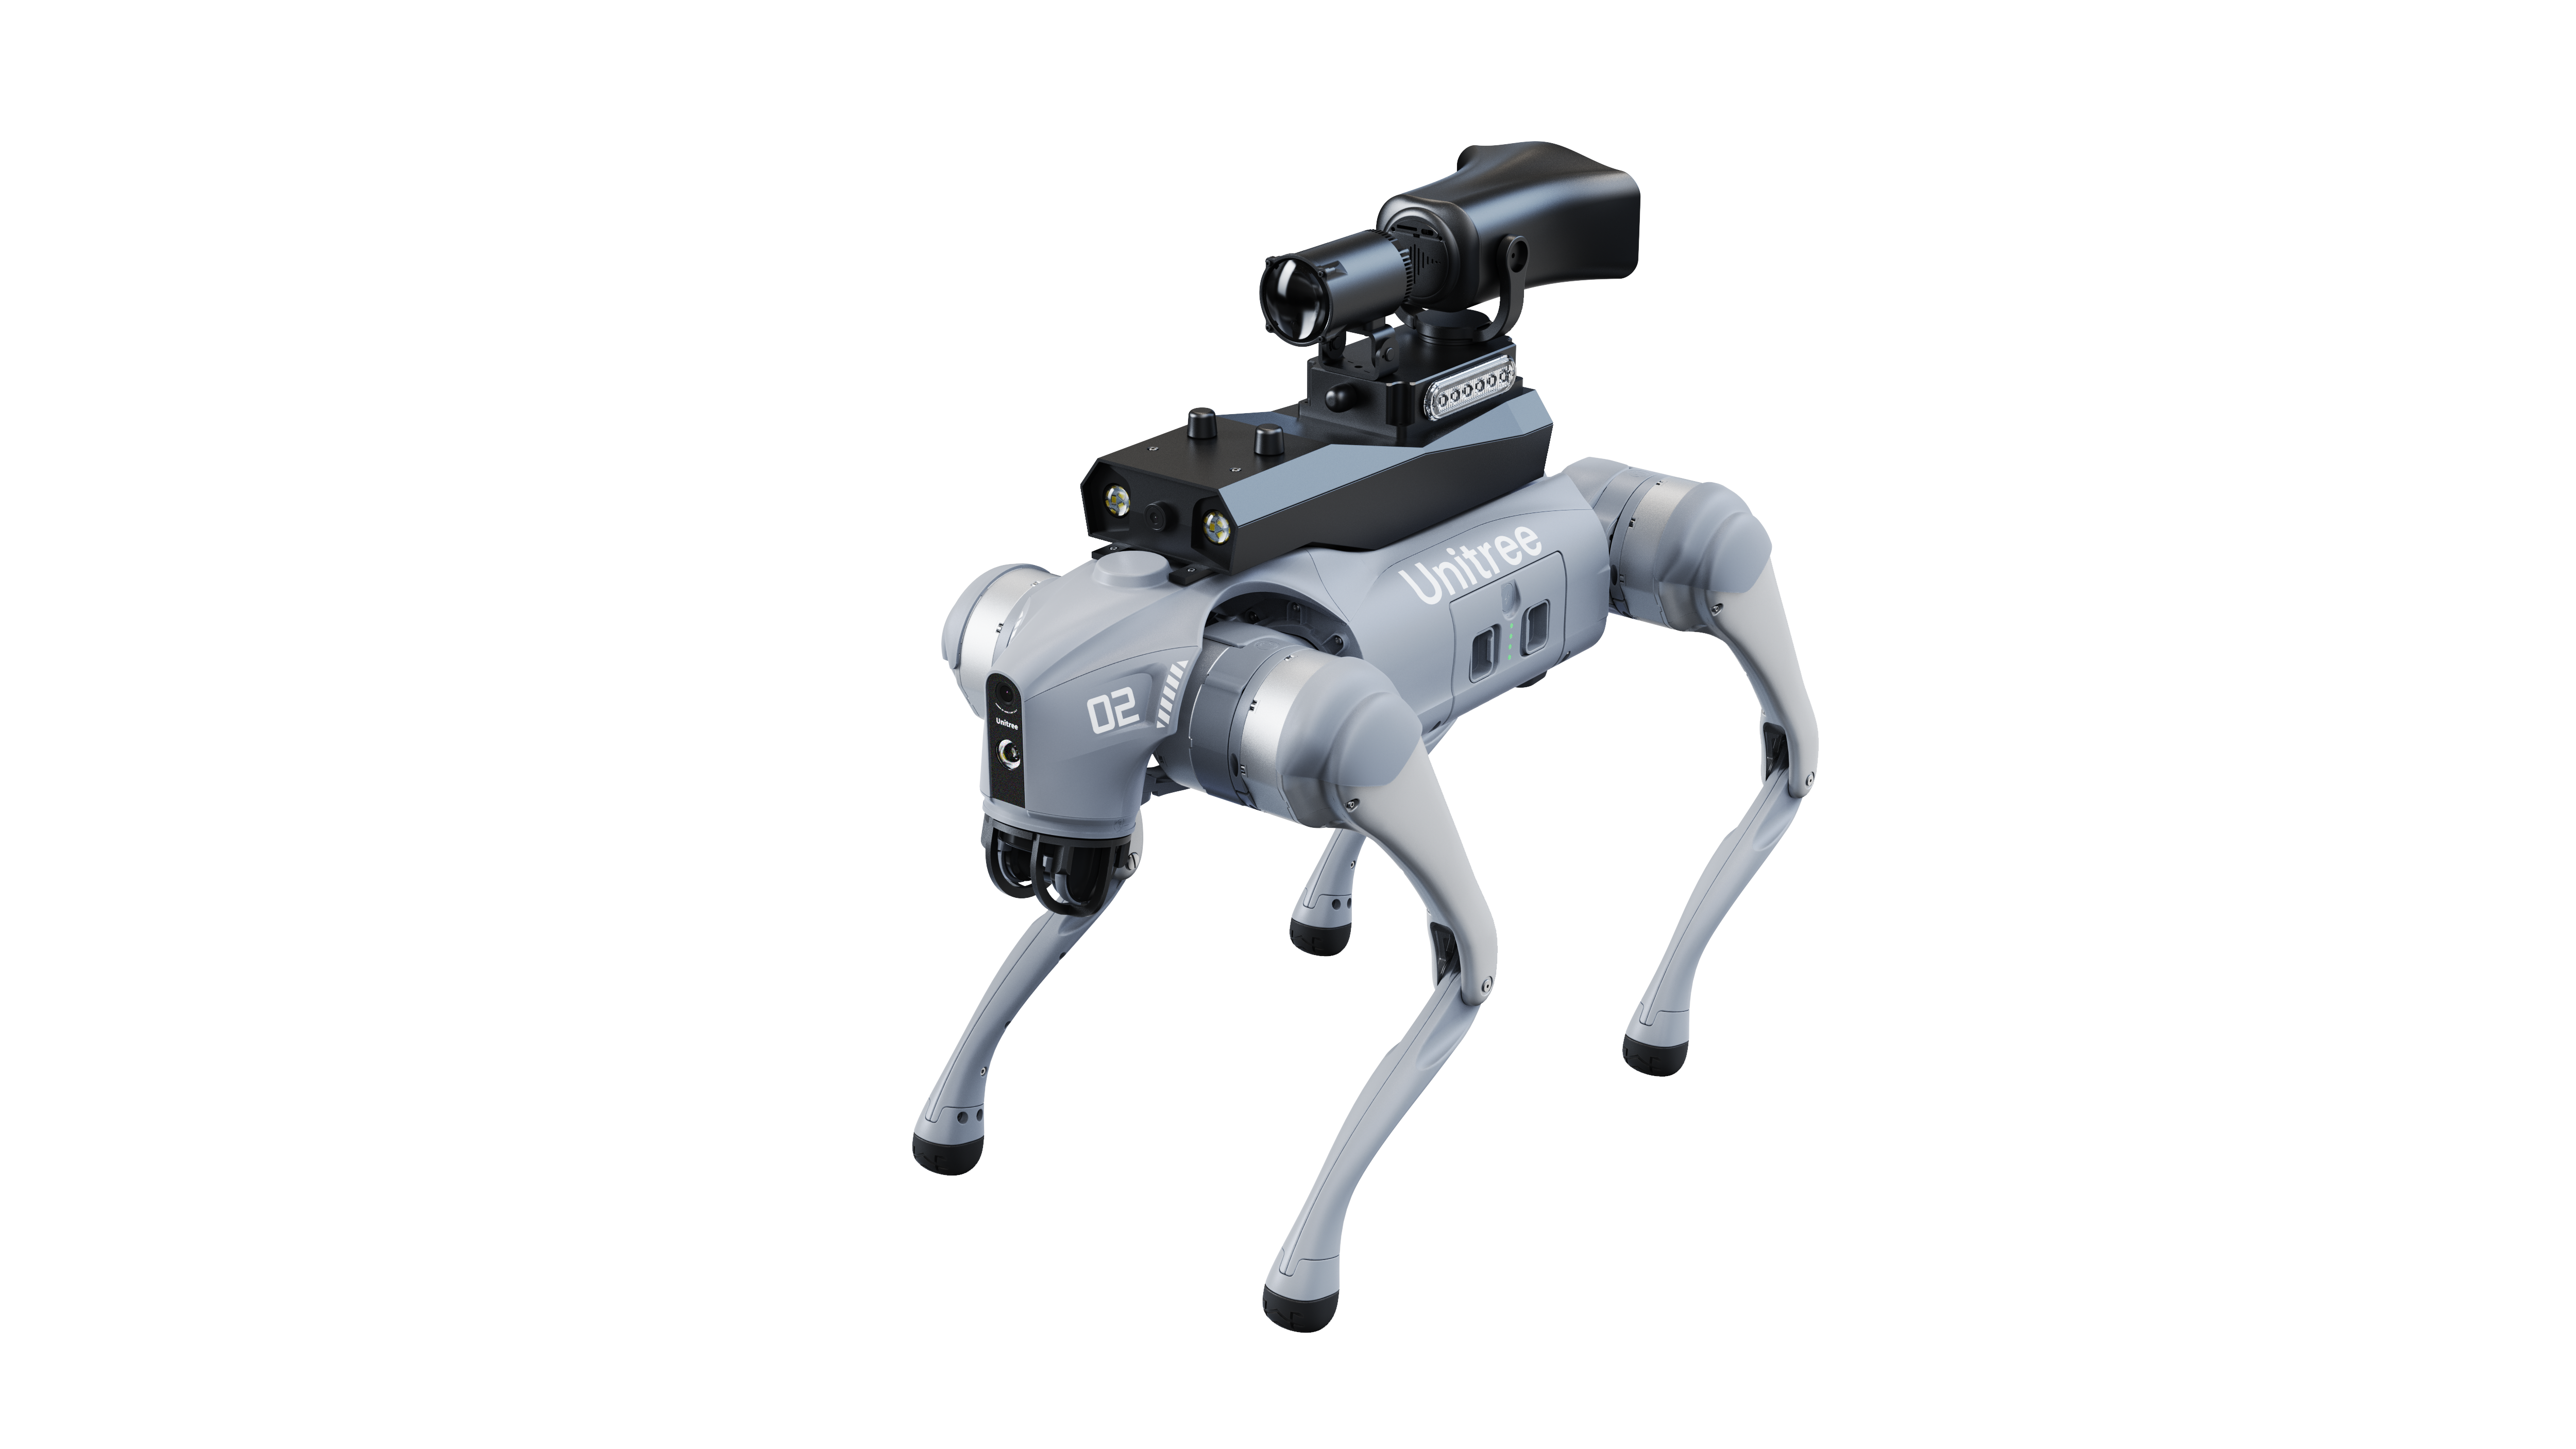
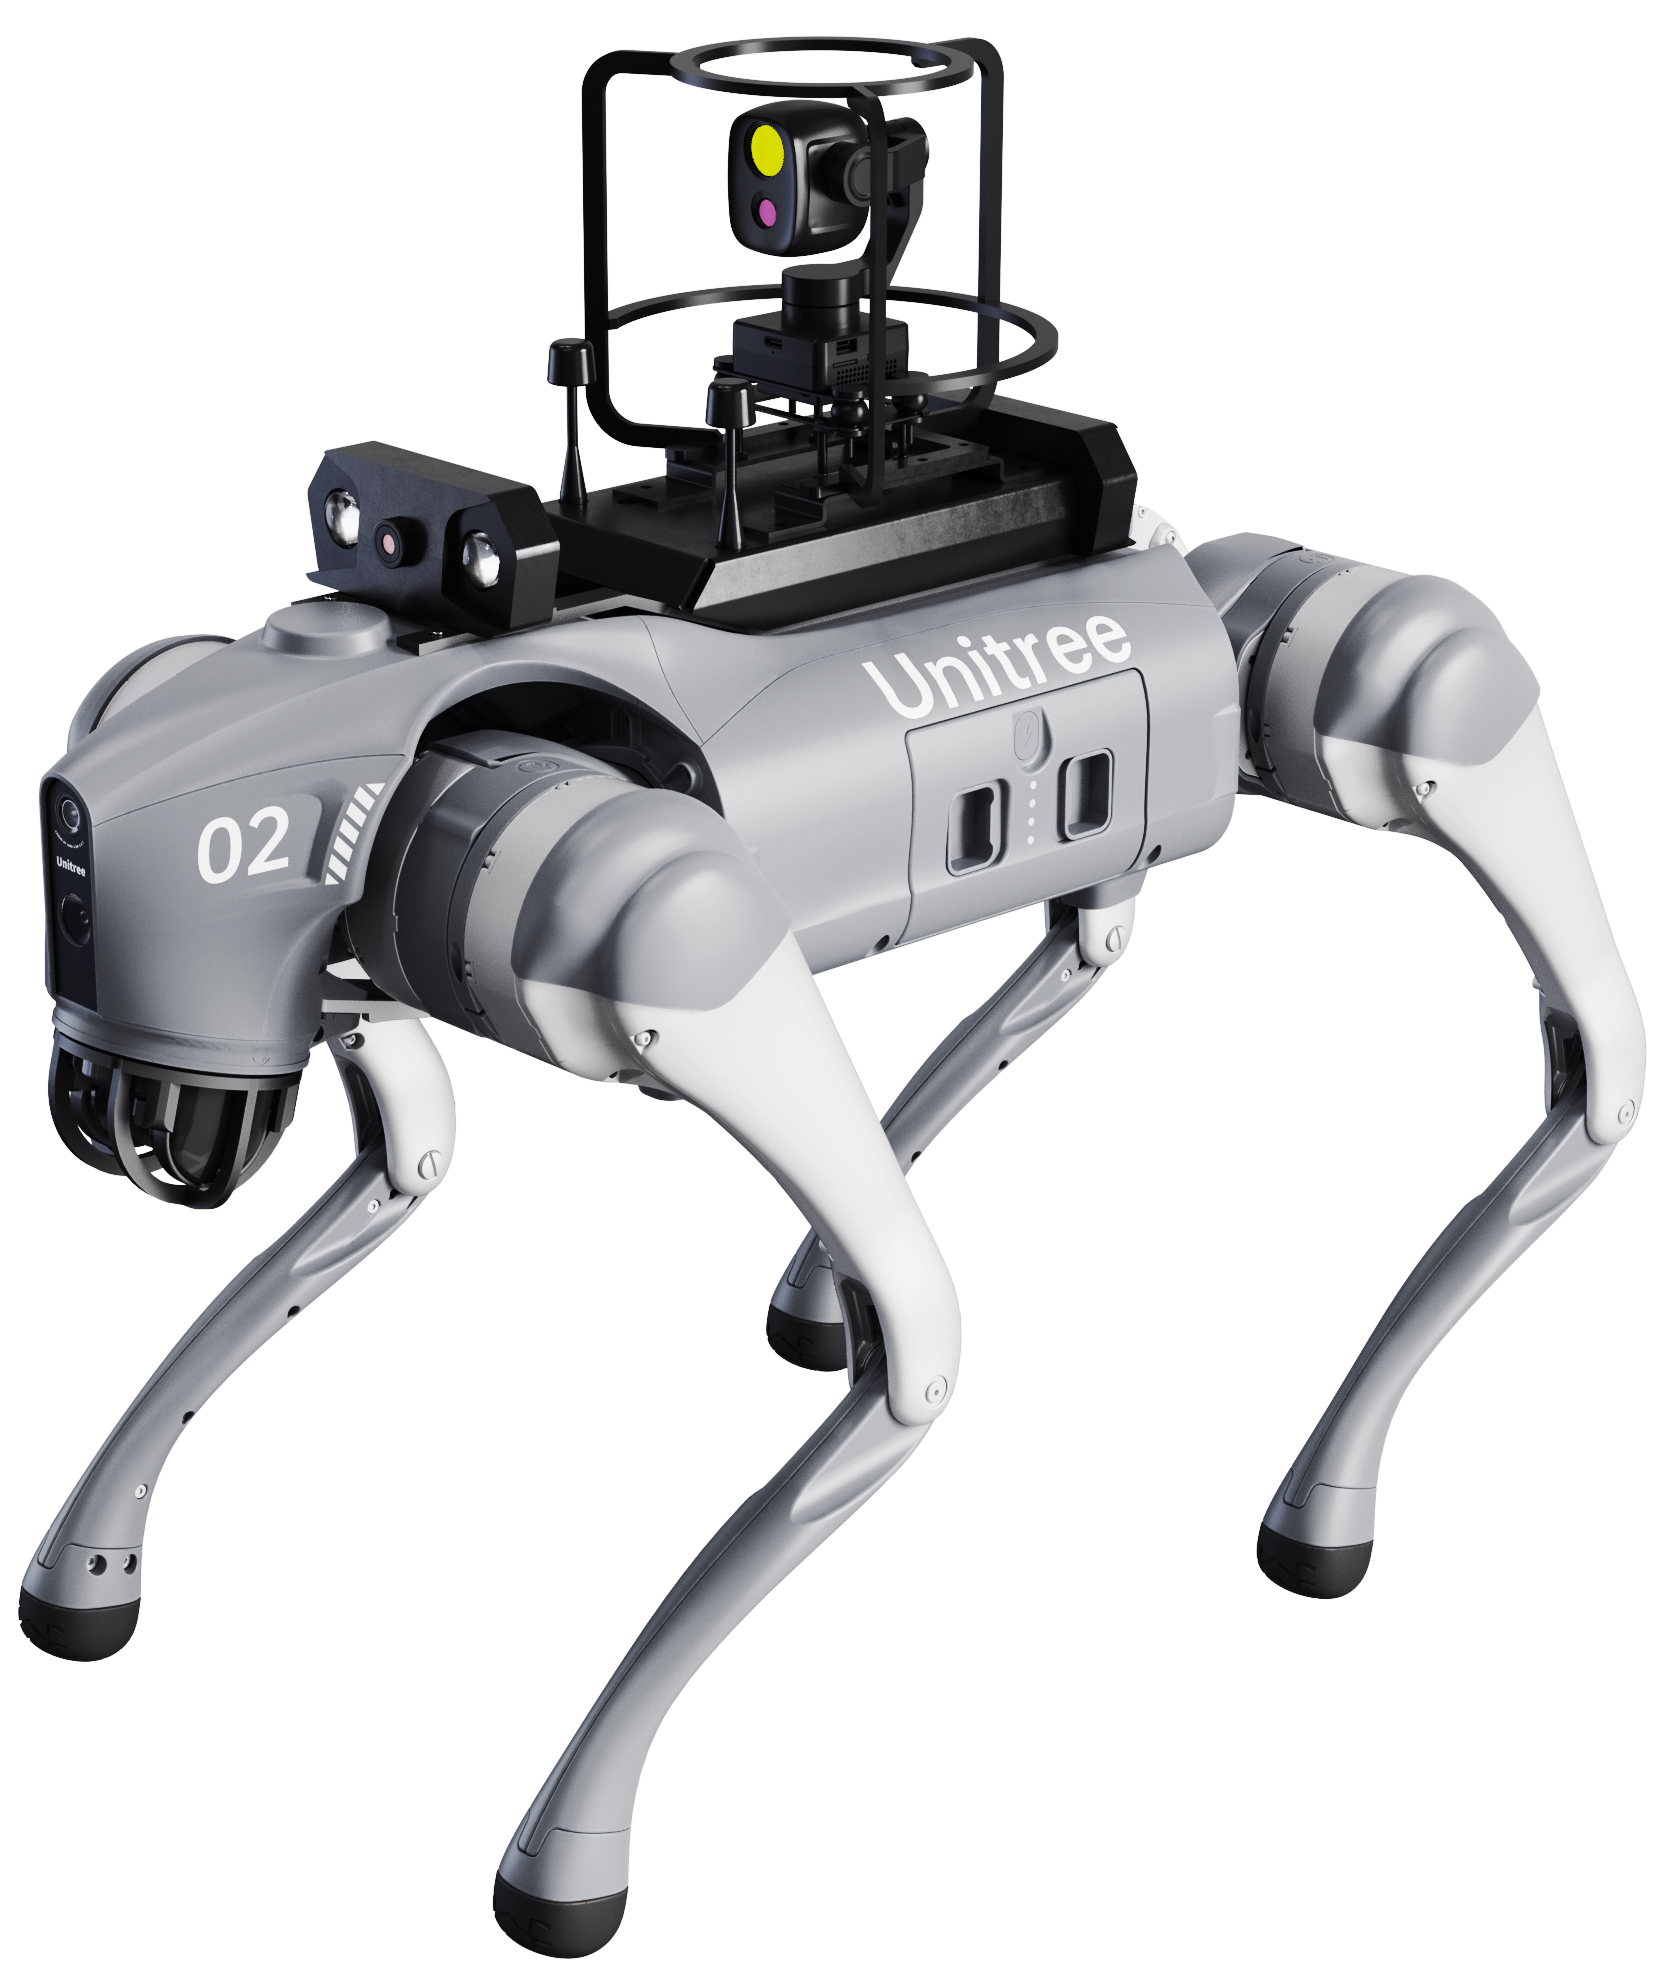
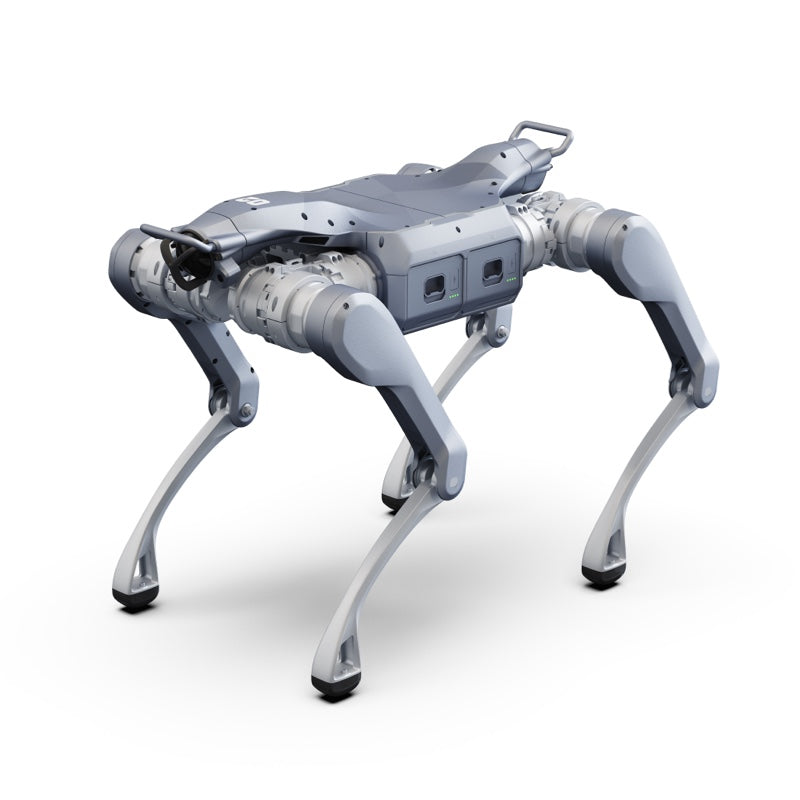
Unitree Go2 Ent Quadruped Robot
Obstacle avoidance
Mission payload options
Rough terrain
Long-range battery
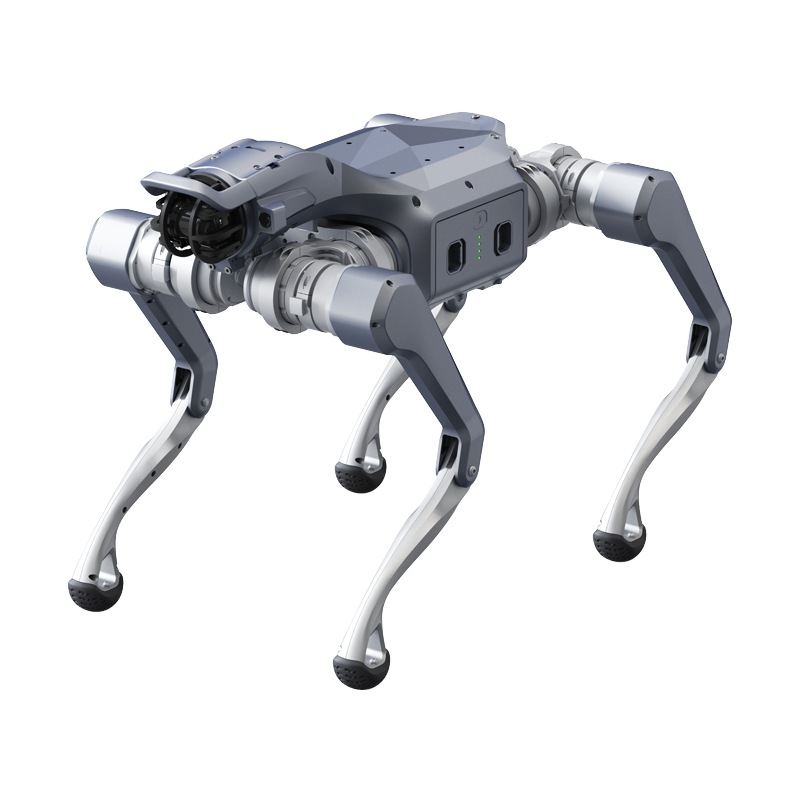
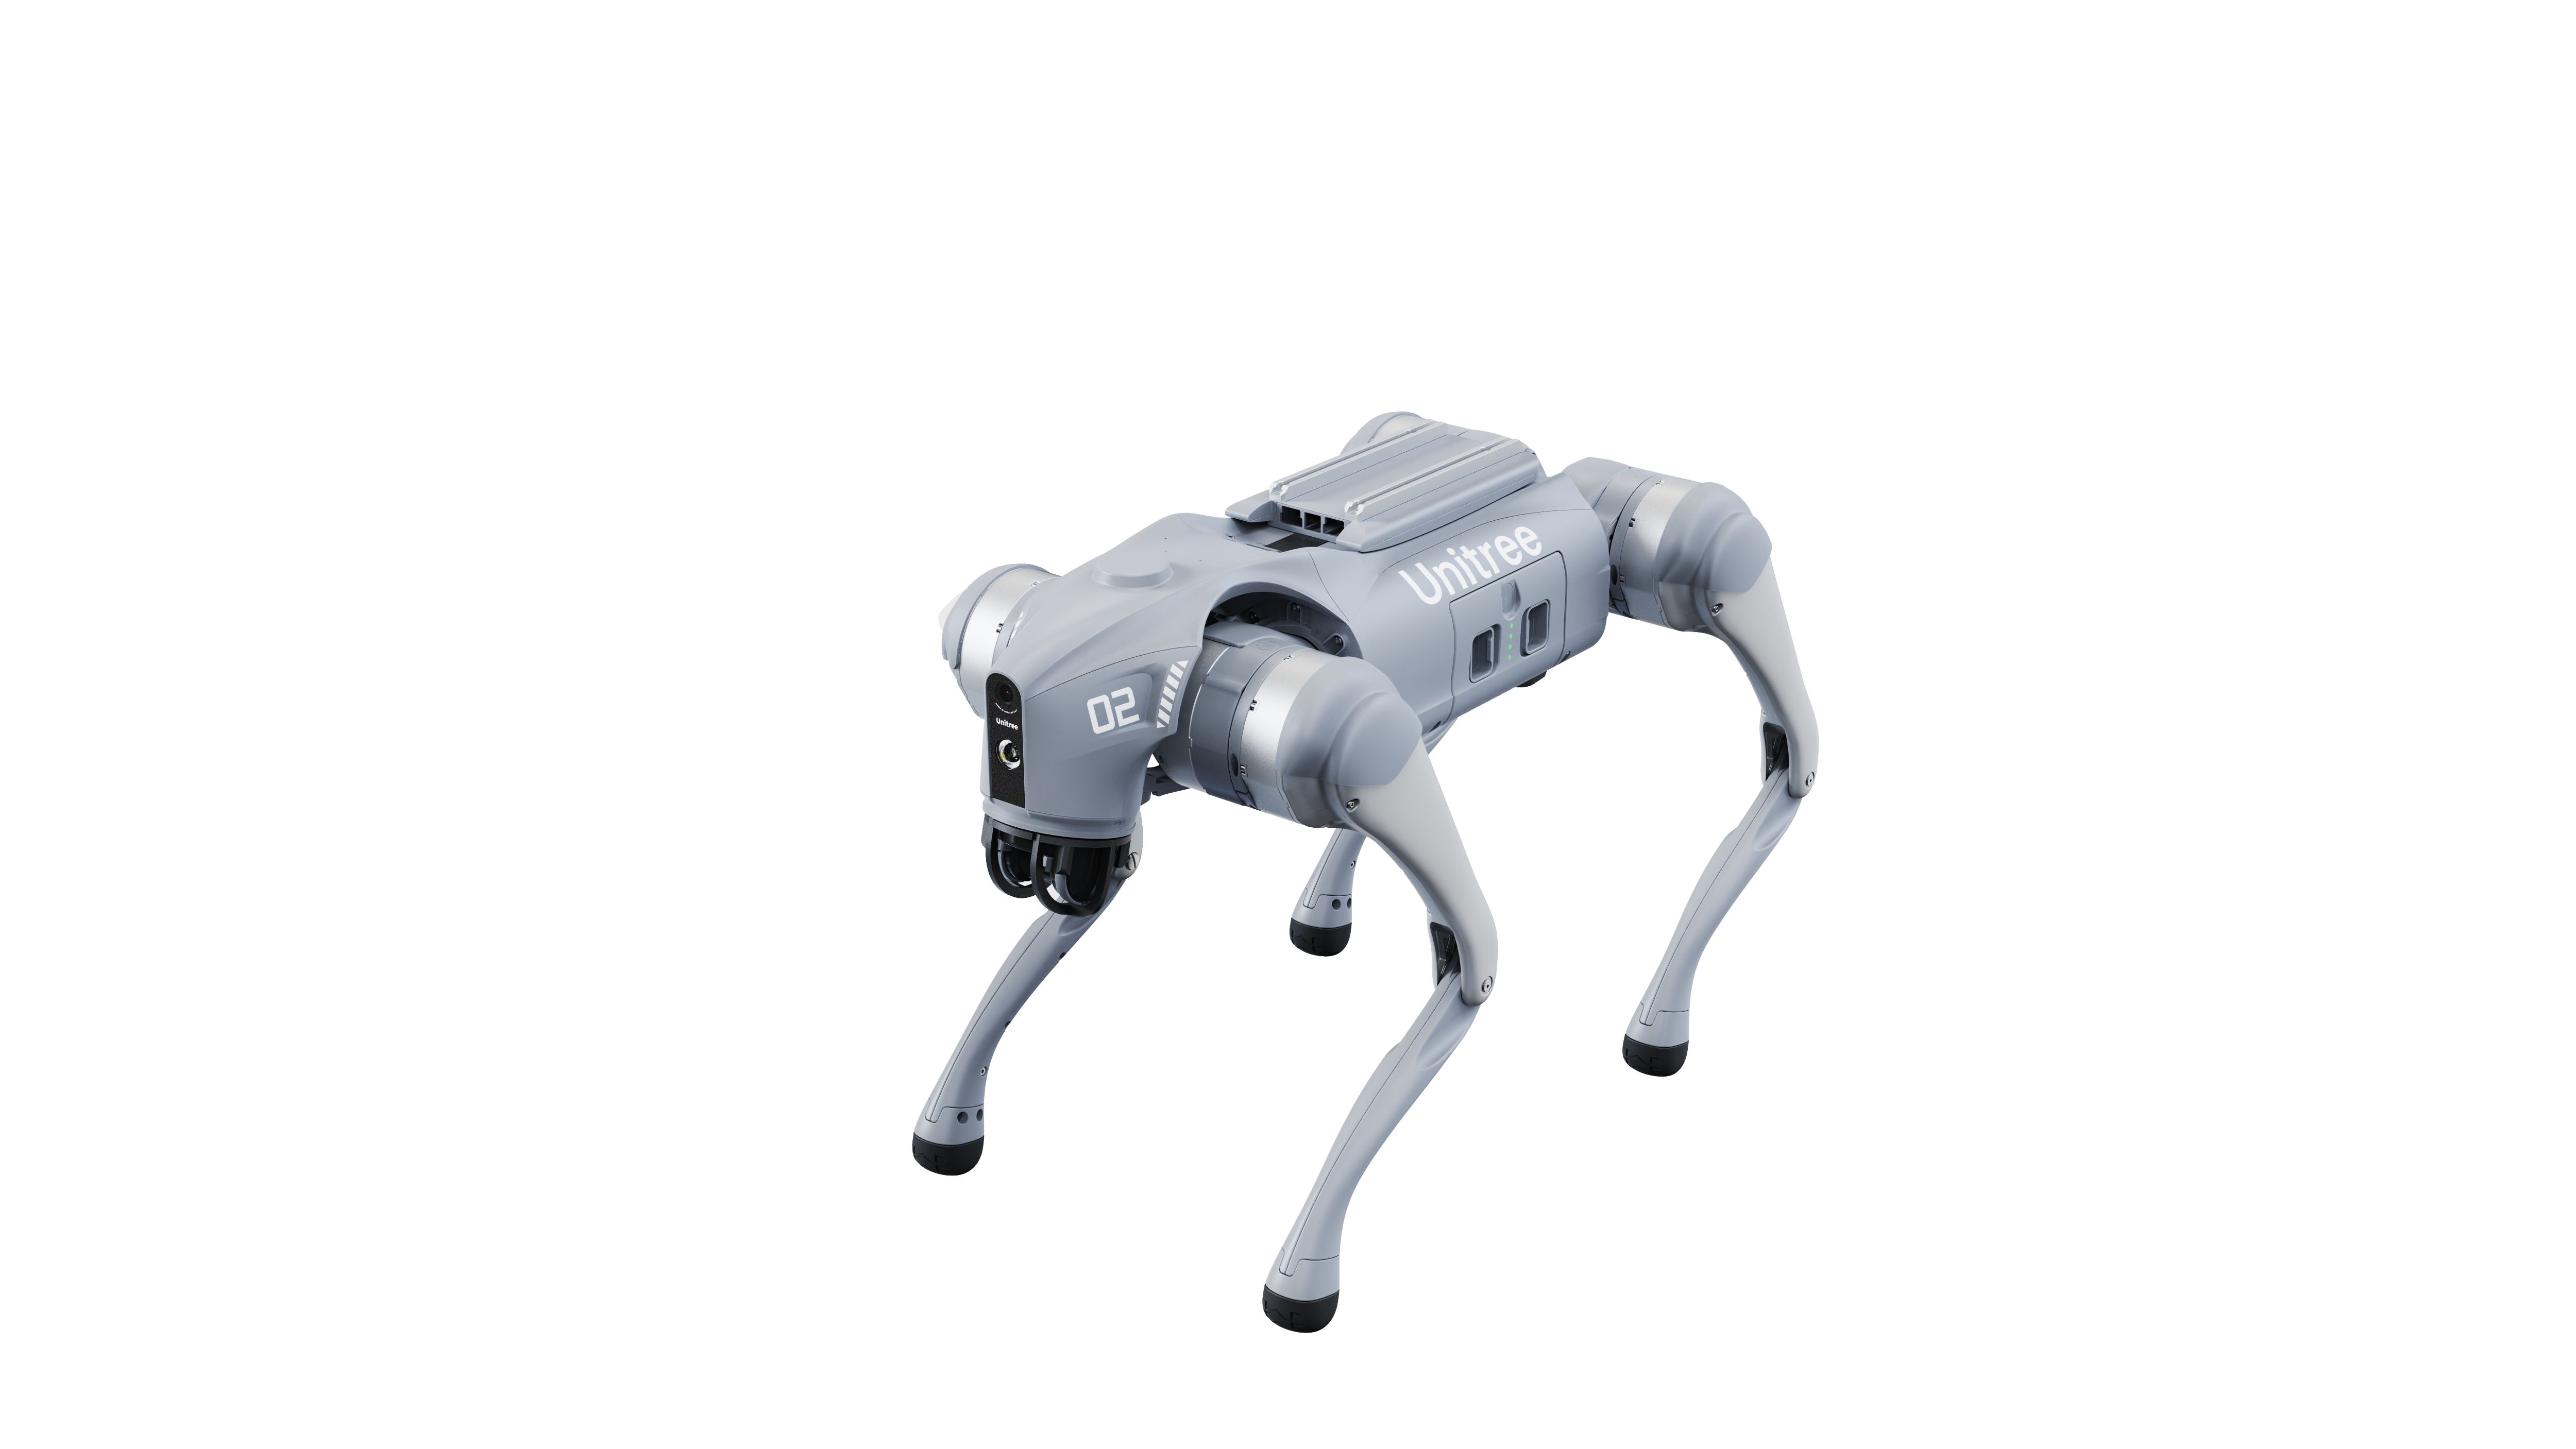
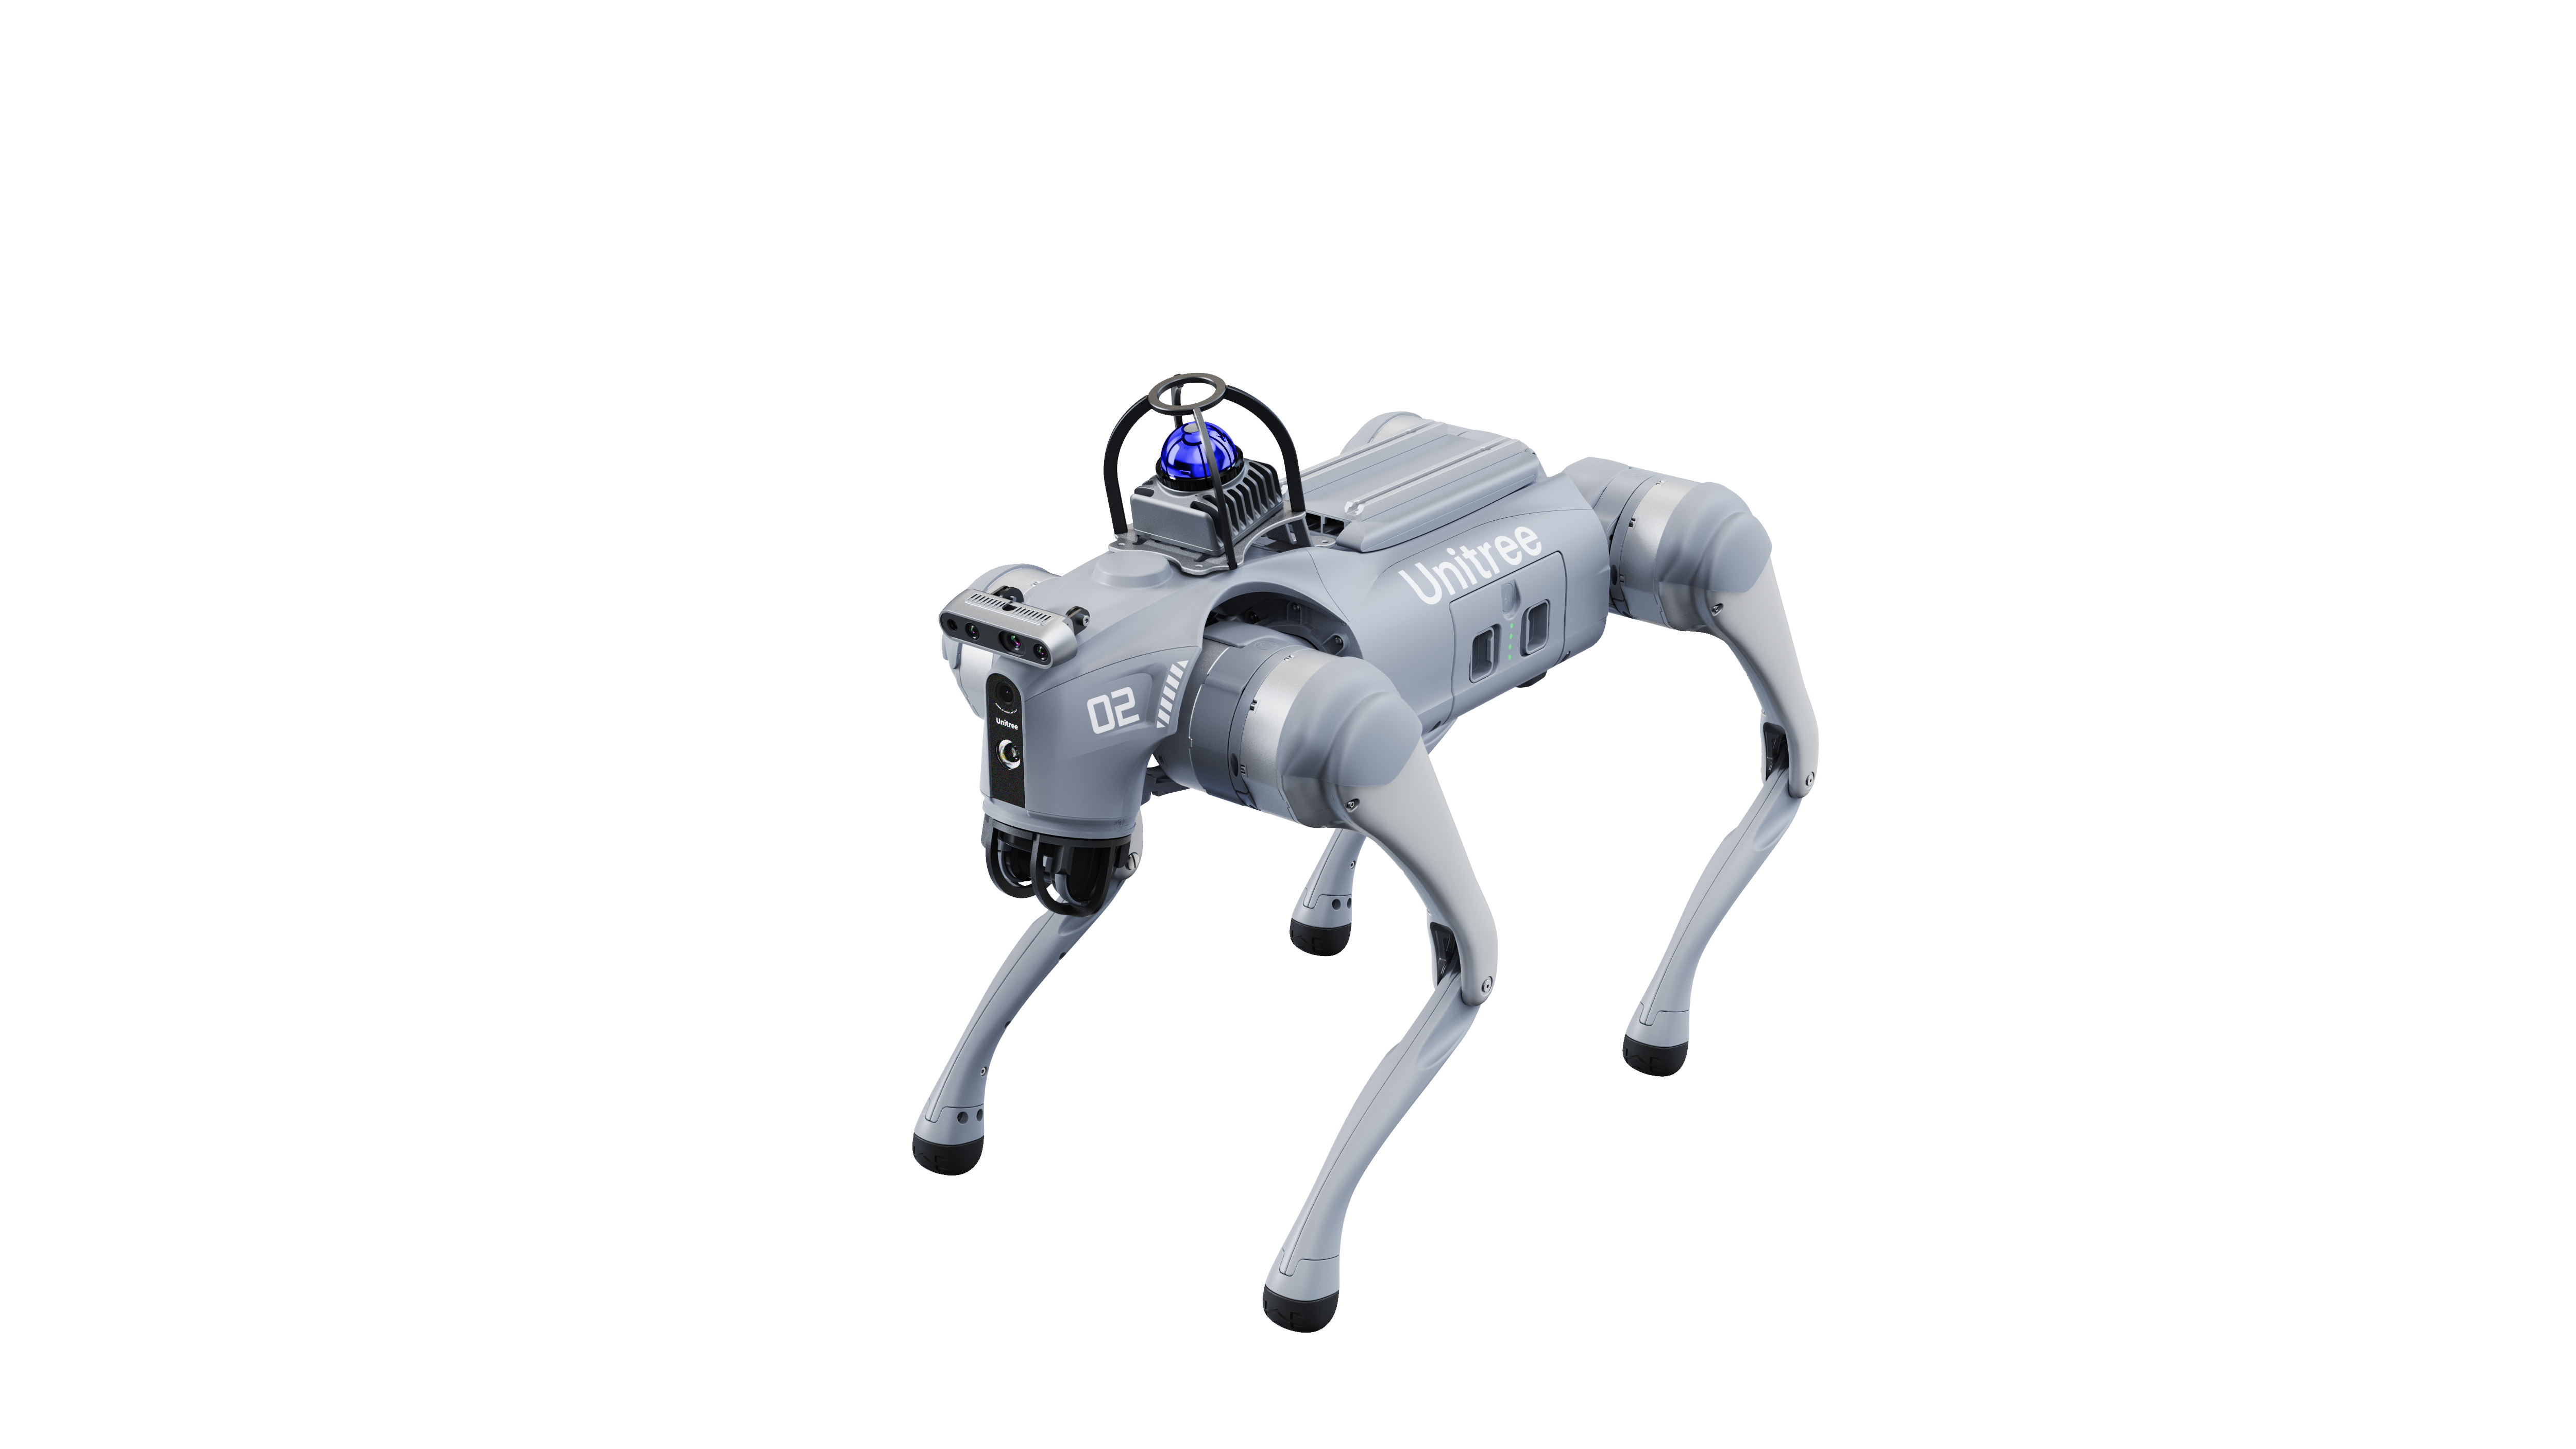
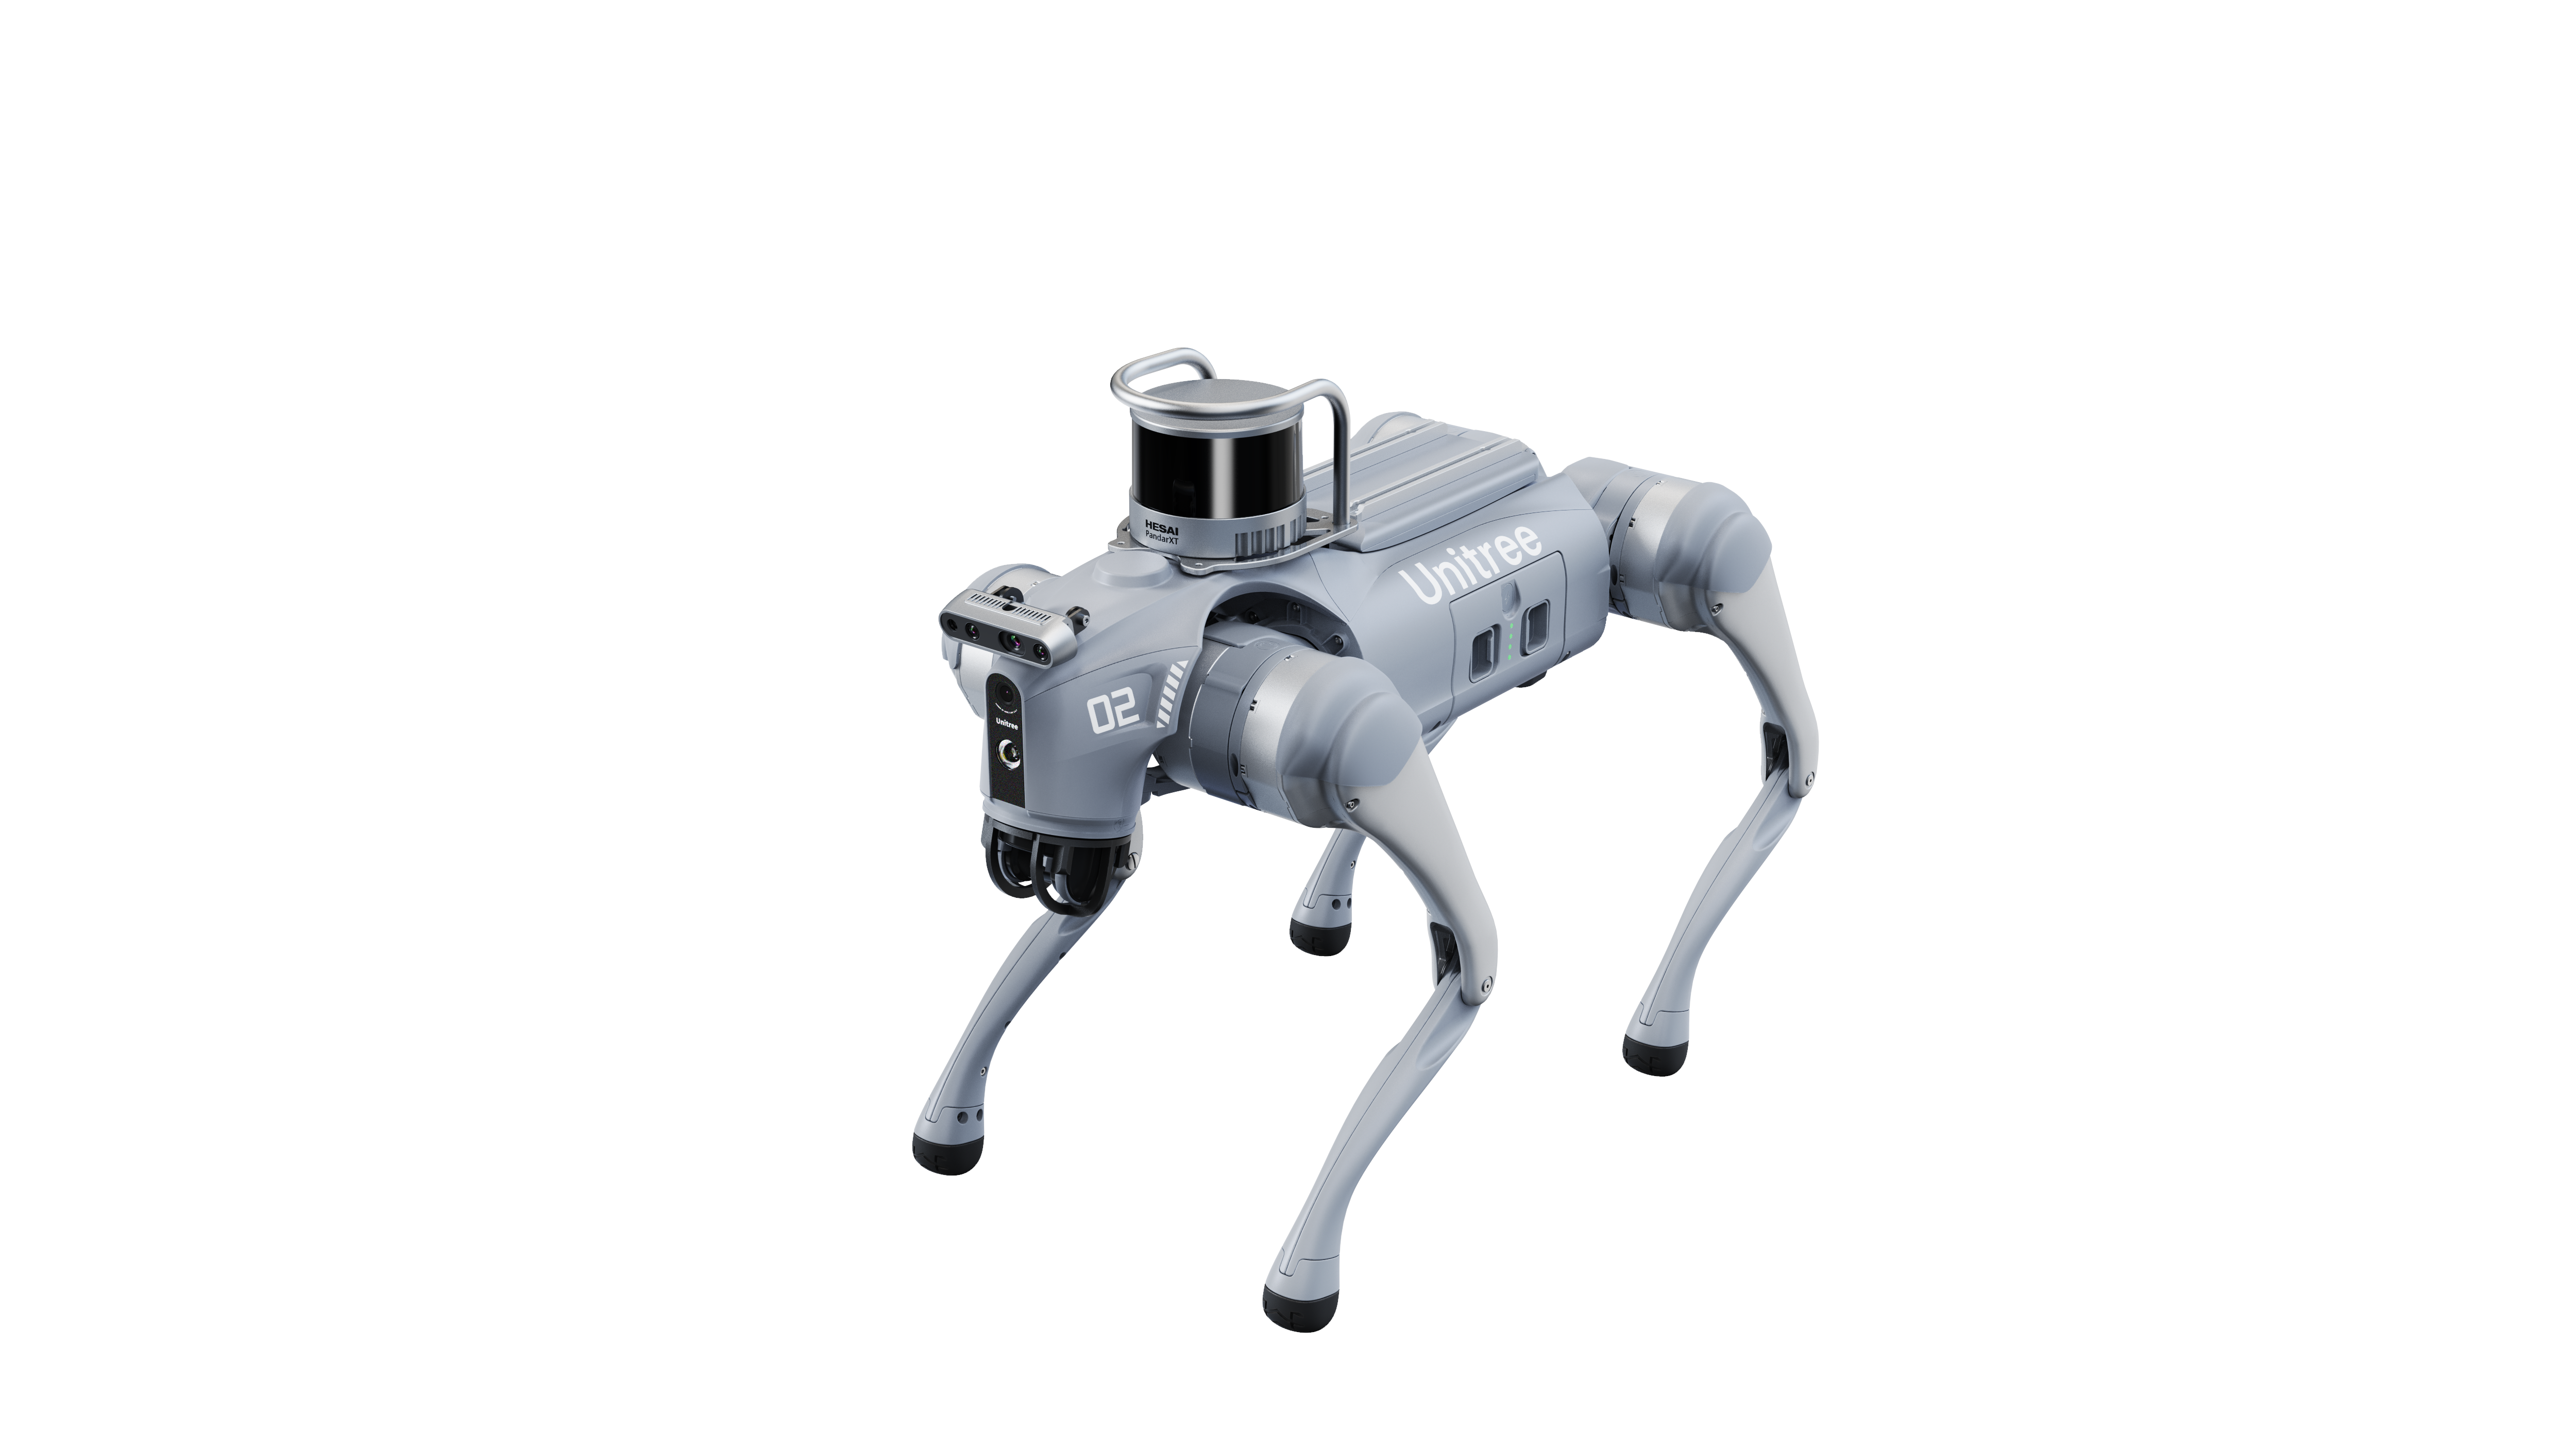
Unitree Go2 Edu Quadruped Robot
Full developer access
Jetson Orin compute
360°×96° perception
Low-level joint control


Max speed
360° perception
Joint motors
Terrain capability


Max speed
360°×96° perception
Precision joint motors
Max terrain climb


Optical zoom
All-weather optics
Low-light rating
Payload weight


ViewPro A30TR-50M Gimbal Camera
Optical zoom
Thermal resolution
Laser rangefinder
AI tracking


Thermal resolution
Vehicle detection
AI tracking
Thermal sensitivity


Optical zoom
Thermal resolution
People & vehicles
Thermal lens


Charged at once
Charge time
Max power rating
Case weight


Charged at once
Charge time
Max power rating
Case weight


Charged at once
Charge time
Max power rating
Case weight


Charged at once
Charge time
Max power rating
Case weight


Charged at once
Charge time
Max power rating
Case weight


Charged at once
Charge time
Max power rating
Case weight


Charged at once
Charge time
Max power rating
Case weight


Charged at once
Charge time
Max power rating
Case weight